

NET-CPU-BASE/PRO – Base module for modular measurement modules (Modbus TCP-compatible)
The NET-CPU-BASE/PRO is the central base module for a modular Modbus TCP remote I/O system in the DEDITEC NET series. Via Ethernet with TCP/IP and Modbus TCP, the interface unit connects modular I/O submodules for the decentralized acquisition and output of digital and analog signals. Typical applications include industrial automation, decentralized data acquisition, mechanical engineering, test benches, and control cabinet integration.
Price range: € 288,58 through € 347,48 Incl. 19% VAT plus shipping
Our promise to you
Product Description
The NET-CPU-BASE/PRO is the central base module of the DEDITEC NET series for building modular measurement, control and automation systems. As an interface and communication unit, the module connects Ethernet/TCP/IP-based networks with modular I/O submodules, forming the foundation of a modular Modbus TCP remote I/O system. Digital and analog signals are acquired and output decentrally via suitable I/O submodules and integrated into higher-level measurement, control or automation environments.
System Role in Modular Remote I/O Architectures
Within the NET series, the NET-CPU-BASE/PRO assumes the central communication and interface role. While the I/O submodules represent the respective signal level, the base module provides the connection to the network and control level. This creates a scalable remote I/O architecture in which inputs and outputs can be added as needed and placed close to machines, test benches, control cabinets or system areas.
Ethernet, TCP/IP and Modbus TCP as Communication Basis
At the core of system integration is the Ethernet interface with 10/100 Mbit/s Ethernet, TCP/IP and Modbus TCP. LAN configuration can be performed via the ICT tool; the IP address can be assigned via DHCP or configured statically. For industrial network environments, the Ethernet interface is galvanically isolated up to 1.5 kV AC for 1 minute. DIP switches support functions such as DHCP ON/OFF, write protection, start with factory settings and bootloader start. The average access speed from the PC to the module is 1 ms, measured with 1000 accesses via the DELIB driver library.
Flexible Interfaces for Different Integration Tasks
In addition to Ethernet/TCP/IP and Modbus TCP, further interfaces are available depending on the variant for configuration, data communication and system integration. The USB interface is implemented as a Type-B connector and supports USB 2.0 / USB 1.1 with up to 480 Mbit/s. The NET-CPU-PRO-CS additionally offers a CAN interface with CAN 2.0A or 2.0B, data rates from 10 kbit/s to 1 Mbit/s, galvanic isolation up to 500 V, open CAN protocol and automatic processing of CAN packets in Auto-TX/RX mode. RS-232 and RS-485 are also available via a 9-pin D-sub connector. The RS-232 interface supports up to 115,200 baud and can be configured via the ICT tool or additionally via DIP switches. The RS-485 interface also supports up to 115,200 baud, is based on the TIA/EIA-485-A standard and is galvanically isolated up to 500 V.
Modular Signal Level with I/O Submodules
The NET-CPU-BASE/PRO itself provides the central interface and communication level. The actual signal type is determined by the connected I/O submodules of the NET series. This allows digital inputs, digital outputs, analog inputs, analog outputs or other I/O functions to be combined as required. This separation between communication unit and signal level simplifies the step-by-step construction of modular I/O stations and reduces effort when applications need to be expanded or adapted later.
Reliable Signal Processing, Diagnostics and Controlled Processes
For industrial applications, the NET-CPU-BASE/PRO supports functions that simplify diagnostics, process monitoring and defined workflows. Event control enables linking events with actions according to an if-then logic. The FIFO function can buffer measurement data and supports smoother transmission of continuous measurement values. Timer functions allow automatic switching of outputs within defined time intervals. Status LEDs indicate communication, module status, interface state, error events, input state changes and timeout shutdowns. This makes the system suitable not only for pure data acquisition but also for decentralized monitoring, control and diagnostic tasks.
Typical Applications
- Decentralized data acquisition in industrial systems and machines
- Modular remote I/O stations with Ethernet, TCP/IP and Modbus TCP
- Test bench setups with distributed digital and analog signals
- Control cabinet integration with modular I/O expansion via DIN rail bus
- Measurement, control and automation tasks in mechanical engineering
- Ethernet-based process data acquisition in SCADA-related or edge-oriented environments
- Test, diagnostic and development environments with flexible I/O structure
Integration, Configuration and Operation
Integration is primarily performed via Ethernet with TCP/IP and Modbus TCP. The DEDITEC ICT tool is available for setup, LAN configuration, testing, diagnostics and firmware updates. Additionally, control can be performed via the DELIB driver library in various programming environments. This allows the NET-CPU-BASE/PRO to be integrated into existing industrial networks, measurement systems, test bench architectures, SCADA-related environments and other higher-level automation structures. The combination of central base module, modular I/O submodules and multiple communication interfaces supports a flexible remote I/O architecture for industrial applications.
Made in Germany
DEDITEC develops and manufactures industrial I/O, control and measurement modules in Germany. For the NET-CPU-BASE/PRO, Made in Germany means product-focused development, transparent technical documentation and a design intended for use in industrial measurement, control and automation applications.
Technical Data
The NET-CPU-BASE/PRO is the central base module of the DEDITEC NET series for building a modular Modbus TCP remote I/O system. Via Ethernet with TCP/IP and Modbus TCP, the interface unit connects industrial networks with modular I/O submodules. Depending on the submodules used, digital and analog signals can be acquired and output decentrally and integrated into measurement, control and automation environments.
At a Glance
- Central base module for a modular Modbus TCP remote I/O system of the DEDITEC NET series
- Interface and communication unit for modular I/O submodules
- Ethernet interface with 10/100 Mbit/s Ethernet, TCP/IP and Modbus TCP
- LAN configuration via ICT tool, IP address via DHCP or static
- DIN rail bus / NET bus for connecting additional NET modules
- Supply voltage: +7 V DC … +24 V DC
- Current consumption: max. 90 mA / 24 V
- Micro SD card slot and battery-buffered real-time clock
- USB Type-B interface with USB 2.0 / USB 1.1 up to 480 Mbit/s
- CAN interface with CAN 2.0A / CAN 2.0B, open CAN protocol and Auto-TX/RX mode
- Raw CAN
- RS-232 and RS-485 interfaces with up to 115,200 baud
- Event control, FIFO function, A/D software filter, timer function and fail-safe function
- DIN rail mounting 35 x 7.5 mm
- Operating temperature: +10 °C … +50 °C
- Dimensions: 117 mm x 22.5 mm x 111 mm (H x W x D)
Interfaces and Integration
- Ethernet interface with 10/100 Mbit/s Ethernet
- Galvanic isolation of the Ethernet interface up to 1.5 kV / AC 1 min
- Modbus TCP for integration into Ethernet/TCP/IP-based automation environments
- LAN configuration via the ICT tool, e.g. IP address and subnet mask
- IP address via DHCP or static configuration
- DIP switches for DHCP ON/OFF, write protection ON/OFF, start with factory settings and bootloader start
- Average access speed from PC to module: 1 ms, calculated with 1000 accesses via the DELIB driver library using the command DapiDoSet32
- USB Type-B interface with USB 2.0 / USB 1.1 up to 480 Mbit/s
- CAN interface via 9-pin D-sub connector
- CAN 2.0A or CAN 2.0B with 1 Mbit/s, 500 kbit/s, 250 kbit/s, 125 kbit/s, 100 kbit/s, 50 kbit/s, 20 kbit/s or 10 kbit/s
- Galvanically isolated CAN interface up to 500 V
- Open CAN protocol (Raw CAN) and automatic processing of CAN packets in Auto-TX/RX mode
- RS-232 interface via 9-pin D-sub connector, up to 115,200 baud, galvanically isolated up to 500 V
- RS-485 interface via 9-pin D-sub connector, up to 115,200 baud, TIA/EIA-485-A standard, galvanically isolated up to 500 V
Modular I/O Expansion and Signal Processing
- NET bus connector for connecting additional NET modules
- DIN rail bus for modular expansion within the NET series
- The power supply also powers the DIN rail bus
- Digital and analog signal processing via suitable I/O submodules
- Suitable for building modular remote I/O stations in control cabinet, machine and test bench environments
- A/D software filter for smoothing and optimizing electrical interference in analog measurement signals
- FIFO function for buffering continuous measurement data and smoother transmission over Ethernet
- Timer function for automatic switching of outputs within a freely definable time period
Fail-Safe, Diagnostics and Operational Safety
- Fail-safe function with software-configurable timeout protection
- Timeout activation time adjustable between 0.1 seconds and 6553 seconds
- Digital outputs can be activated, deactivated or left unchanged in a timeout event
- Timeout mode “Normal” for one-time valid timeout protection with manual reactivation
- Timeout mode “Auto reactivate” for automatic reactivation after communication with the control PC is restored
- Timeout mode “Secure Outputs” for locking output access after a timeout event
- Status LEDs for DIN rail bus communication, module status, Ethernet activity, USB activity, interface status, error, input state change and timeout shutdown
- CAN activity and SER activity as LED indicators on the NET-CPU-PRO-CS variant
Mechanics and Environmental Conditions
- Supply voltage: +7 V DC … +24 V DC
- Current consumption: max. 90 mA / 24 V
- External memory: Micro SD card slot
- Real-time clock: battery-buffered, CR2032
- Phoenix Contact 1893313 terminal block for power supply connection
- For conductor types from 0.2 mm² … 2.5 mm²
- Pluggable terminal block
- DIN rail mounting: 35 x 7.5 mm
- Operating temperature: +10 °C … +50 °C
- Dimensions: 117 mm x 22.5 mm x 111 mm (H x W x D)
- General
- Technical data
- ICT-Tool
- Configuration
- Configuration CAN
- Configuration serial
- Modbus
- M2M
- FIFO
- Event-Control
- Controlling CAN
- Controlling serial
- DELIB-API commands
- WEB interface
- App
- Connectors
- Downloads & manuals
- Scope of delivery
- Accessories
USB interface with Plug & Play
Thanks to Plug & Play, our modules with USB interface are automatically recognized and are immediately ready for use without any configuration. Configuration is only required if several USB modules from the same product series are used on the same system.
Automatic Transmit and Receive Mode
Use our Auto TX/RX mode to automate the workflow of your DEDITEC product by automatically processing CAN packets received from other nodes in the network or transmitting CAN packets to them. Both RAW CAN and J1939 are supported. Using our free ICT tool, you can define how TX and RX packets are to be processed via a graphical user interface.
Plug connector
A screwless system from the manufacturer WAGO® Kontakttechnik is used as the connector. The 1-wire female connectors are 100 % protected against mismating and have an ejection and locking mechanism.

Easy installation thanks to DIN rail bus
Thanks to the practical bus connector, which is clipped into the DIN rail, individual modules of a system can be added or replaced very easily. This Plug'n Play principle makes commissioning easier for you and eliminates the need for tedious wiring.

LEDs
Each digital input and output has a separate LED that lights up when the signal status is active. The status of the operating voltage, communication with the interface, error events or the occurrence of a timeout can also be displayed.

FIFO („First in-First out“)
Using the FIFO feature, measured values can be collected and stored in a buffer and then forwarded in packets to the interface or submodules at regular time intervals. This eliminates delays caused by traffic, spatial distances or other disruptive factors and significantly improves measurement processes.

M2M
Machine-to-machine, or M2M for short, involves direct communication between two or more modules. Analog or digital input signals from one transmitter module can be automatically transmitted to another module on a channel-by-channel basis.
M2M transmission is supported by all our products in the WEU series or by products with a CAN interface.

Event-Control
This function can be used to implement small control tasks that are saved in the module. These control tasks are configured as events and actions and then executed automatically according to the “if-then” principle.

Software and control for programmers
Our supplied DELIB driver library makes it easy to address the product via our API in almost all programming languages under Windows and Linux.
We offer support for the following programming languages:
- C
- C++
- C#
- VB
- VBA
- VB.Net
- Java
Remote switching of IP modules
Our IP modules can be conveniently and easily controlled worldwide via the TCP-IP network. The following options are available to you.
DEDITEC I/O Control app
With our DEDITEC I/O-Control app, our modules can also be controlled remotely. All you need is the network configuration of the module. The app is available for iOS and Android smartphones.
Web interface
Our IP modules can be operated from any browser. All you need is the IP address of the module.
M2M
Our WEU series modules can establish direct M2M communication with any DEDITEC Ethernet product, enabling, for example, the automated transmission of measured values or remote monitoring of machines and systems.
ICT-Tool
With the help of our all-in-one ICT-Tool software, you can configure, update, control and test your DEDITEC modules quickly and easily. The tool is included in the DEDITEC driver library.

More security through encryption
With the DEDITEC encryption mode, all TCP communication from the control PC to the DEDITEC module can be encrypted. This prevents unauthorized access to the module via TCP by third parties.
Control modules via Modbus TCP
Modbus TCP enables standardized data exchange between controllers, measuring devices, drives, and higher-level systems, regardless of the manufacturer. Status and measured values are read or written via the open Modbus register protocol.
Command-Line-Interface
With the help of the command line interface, or CLI for short, our products with Ethernet or USB interface can be easily addressed via the command line. Our digital and analog inputs/outputs are supported. The CLI is available for Windows and Linux operating systems.
General information
| Power supply | +7 V DC ... +24 V DC (also serves as power supply for the DIN rail bus) |
|---|---|
| Power consumption | Max. 90 mA / 24 V |
| External memory | Micro SD card slot |
| Real time clock | Battery-buffered (CR2032) |
| LEDs |
*Only for the NET-CPU-PRO variant |
| Timer function | Automatic switching on and off of the outputs within a freely definable period of time |
| Connection terminal |
|
| DIN Rail-Bus | NET bus plug connector for connection to other NET modules |
| DIN rail mounting | 35 x 7,5 mm |
| Operating temperature | +10 °C ... +50 °C |
| Dimensions | 117 mm x 22.5 mm x 111 mm (H x W x D) |
Special features
| Event-Control | With our event control, you have the option of linking occurring events to a specific action. With the help of our ICT tool, the control tasks can be stored directly in the module memory thanks to an intuitive “if-then” logic. Monitor, control and regulate without an additional control PC. |
|---|
| FIFO-function | The built-in FIFO-function makes it possible to carry out continuous measurements with the module. The measurement data is first stored temporarily on the module and can then be transferred to the measuring PC at a more constant sampling rate via the Ethernet interface. |
|---|
| A/D-filter | Our A/D software filter can be used to smooth and optimize electrical disturbance variables that affect the measurement signal. The filter principle is based on averaging a sum of measurements. The higher the filter level is selected, the more measurements are used to calculate the average value. |
|---|
Fail-Safe-function
| FAIL-SAFE-function |
|
|---|---|
| Timeout-mode "Normal" | The "Normal mode" is valid once and must be reactivated manually by software command after each timeout event. The customer application still has access to all controller outputs. |
| Timeout-mode „Auto reactivate“ | In “Auto reactivate mode”, the timeout function is automatically reactivated once communication with the control PC has been re-established. The customer application still has access to all outputs of the control unit. |
| Timeout-mode "Secure Outputs" | The “Secure outputs mode” blocks access to the outputs after the timeout event. Unlocking can only be carried out by software command. This is an important safety aspect in the event of a fault. |
Interfaces
CAN Interface
| CAN-Interface |
|
|---|
Ethernet-Interface
| Ethernet-Interface |
|
|---|---|
| IP-address | DHCP or static |
| DIP Switches |
|
| Access speed |
|
USB Interface
| USB-Interface |
|
|---|
RS-232 Interface
| RS-232 Interface |
|
|---|
RS-485 Interface
| RS-485 Interface |
|
|---|
The ICT-Tool
Integration, configuration and testing - Our all-in-one Windows tool contains all the functions you need to put our products into operation quickly, easily and efficiently. Start with the setup and configuration, install firmware updates and use the extensive test and diagnostic options. The integrated help menu provides additional support if required.
Below you will find a brief overview of the program’s basic menus.
Module selection
Here you can integrate a new product into the ICT tool by clicking on the “+” symbol and then configure it.
ICT TreeView
In the TreeView, on the left-hand side of the program window, you can see the respective control elements or functions that are supported by your selected module. The scope of the functions depends on the respective product.
Overview
All relevant module information can be accessed here at a glance.
- Module name
- Module ID
- Firmware revision
- MAC address
- LAN and WiFi Network address (module dependent)
Inputs / Outputs
This overview shows the number of I/Os supported by your module.
Module infos
Here you will find all the important feature information for your module.
General features
Here you will find all the important feature information for your module.
Digital I/O features
Here you will find information about the digital I/Os supported by the module.
Analog I/O features
Here you will find information about the type of analog I/Os supported by your module.
Special I/O features
Here you will find information about the type of special I/Os supported by your module.
In den folgenden Kapitel, würden wir Ihnen unsere neue All-In-One-Software gerne genauer vorstellen.
Info
All relevant module information can be called up here at a glance.
- Module name
- Module ID
- Firmware revision
- Interface type
- Current DIP switch setting (only for Ethernet modules)
Identification
If several DEDITEC Ethernet modules are active in the network, a signal LED on the selected module can be activated via an identification function. This facilitates visual assignment.
Restart
You can restart your module here. The module status shows whether the restart was successful.
USB configuration
If you want to use several USB modules from the same product series on one PC, each of these modules must first be assigned its own module number.
LAN info
On this information page, you will find the current LAN network information and all the settings for your module at a glance.
LAN configuration
Integrate the product into your network or control it directly via a 1-to-1 connection.
The following parameters can be changed.
- Board name
- DHCP on/off
- IP address
- Subnet mask
- Default gateway
- TCP Port
WiFi info
All important WiFi settings are displayed on this page
WiFi configuration
Here you can change the network settings of the selected WiFi product.
The following settings can be made:
- Board name
- WLAN on/off
- Router name
- Router password
WPS
With the WPS function, your module can be connected to the router quickly and easily, automatically (WPS on the router is required)
CAN configuration
With our CAN products in the BS, NET and UC series, settings for the interface and the TX/RX packets can be made using the ICT tool.
More information can be found here:
Serial configuration
For our serial products in the BS, NET, UC and RO series, changes to the interface can be made using the
ICT tool.
More information can be found here:
Modbus TCP
Here you can set the Modbus TCP configuration of the module.
The following configurations can be made.
- Enable/disable access via Modbus TCP
- TCP port
TCP encryption
Here you can make settings for the encryption of your module.
The following configurations can be made.
- Allow unencrypted protocol
- Allow “User” encryption mode
- User password
- Allow “Admin” encryption mode
- Admin password
NTP configuration
You can make changes to the NTP service here.
The following configurations can be made.
- NTP service on/off
- server
- Port
- Timezone
WEB-Login
Here you can change the login settings of the web interface.
The following configurations can be made.
- Session duration
- Login name
- Login password
- Allow I/O access via web interface
D/A Default Values
Here you can set the D/A values and modes with which the module should be started.
The value and mode can be set individually for each channel.
Watchdog configuration
Here you can make and save settings on your watchdog stick.
Save or Load config
Using the “Save or Load config” function, you can save your entire module configuration in an external XML file.
This means you can always load your module in the desired original state.
The following configurations can be saved depending on the module type.
- USB configuration
- LAN configuration
- WiFi configuration
- TCP encryption
- NTP configuration
- Serial configuration
- CAN configuration
Status
This gives you an overview of the activity of the transmitter and receiver module
The following information from the transmitter module is displayed:
- Status of the activity: If the check mark is set, this action is currently being performed.
- Total number of actions performed. Is reset to 0 after a restart of the module.
- Number of actions per second.
- Number of DELIB errors that occur when executing commands from the DEDITEC driver library.
The following information from the receiver module is displayed:
- Connected: If the check mark is set, the transmitter and receiver modules are connected.
- IP address of the receiver module.
- Number of connection attempts.
Receiver modules
You can set the network settings of the receiver module here.
The following settings can be made
- Name for the receiver module
- Network settings of the receiver module
- Timeout
- Encryption type/ password
Action
With an action, you define which input signal is to be sent from the transmitter module to which output of a receiver module.
The following settings can be made:
- Type of task (digital, analog)
- Which receiver module should be used
- The interval at which the operations are to be carried out
- Start channel of the transmitter module
- Number of channels to be transmitted
- Start channel of the receive module
In the image on the right, DI data is sent every 100ms from channel 3(CH Start) to channel 8 ((CH Start) + (CH Count)) to channels 0-5 of the target module.
In den folgenden Kapitel, würden wir Ihnen unsere neue All-In-One-Software gerne genauer vorstellen.
Status
The Status area provides an overview of all active events and executed actions.
The following information is listed:
- Event number
- Event type
- Time interval of the event
- Number of events that have occurred
- Action number
- Number of triggered actions
- Number of other actions
Events configuration
Up to 16 different events can be created in the configuration menu. An event can be used, for example, to define switching thresholds at the analog inputs or logical states at the digital inputs of the module and link them to an executable action. The configuration itself is saved permanently in the module configuration memory of the module.
The following event modes are available, depending on the module type:
- DI: High-Low state of a digital input.
- DI flip-flop: Status change of a digital input (is stored in the module with the so-called flip-flop flag and deleted again after readout).
- DO readback: ON-OFF status of a digital output (is read out using a DO readback command).
- A/D: Current or voltage level at the analog inputs
Configuration actions
Up to 16 different actions can be created in the configuration menu. An action defines what should happen within an event after a condition is met.
The following action modes are available, depending on the module type:
- Set DO output: Switches a digital output on or off
- Set D/A output: Outputs a current or voltage value at an analog output
- Send CAN packet: A special CAN TX event is triggered (up to eight CAN TX events can be configured separately).
Digital Out
Hier können Sie die digitalen Ausgänge Ihres Modules ein- und ausschalten.
Folgende Funktionen können in dieser Form getestet werden.
- Kanalweise Ein- und Ausschalten der digitalen Ausgänge
- Readback der Kanäle
- Setzen eines Digitalausgangs für eine bestimmte Zeit (Modulabhängig)
- Gibt an welchen Status die Kanäle nach Ablauf der Zeit einnehmen sollen (Modulabhängig)
- Testen der Ausgänge
Digital Out
All digital outputs of your product can be checked by clicking on the buttons.
The following switching options are possible:
- Switching on and off channel by channel
- Channel-by-channel switching on or off for a specific time (product-dependent)
- Reading back the switching status (readback)
Digital In
In this view, the logical states of all optocoupler inputs can be read out.
The following information is displayed:
- Logical status of the inputs (ON/OFF)
- Number of detected pulses (counter function)
- Change of state detected (flip-flop)
TTL I/O
In this menu, the TTL channels of the module can be configured as inputs or outputs. The individual TTL outputs can be switched on or off by pressing the buttons. In addition, the status of all TTL inputs can be read out.
The tool offers the following functions:
- Configuration of the channels as input or output (in blocks of 8)
- Switching on and off channel by channel
- Reading back the switching status (output readback)
- Displaying the logical status of the inputs (input readback)
Analog Out
Here you can test the analog outputs of the module and manually enter any voltage or current value.
Analog In
In this menu, voltage or current values of all A/D channels can be displayed.
It is also possible to activate our A/D software filter with different filter levels.
CAN Runtime Parameter
Here you can change the CAN settings of the interface, the RX and TX packets in runtime.
The following settings can be made:
- Baud rate
- Extended ID
- Active on/off
- CAN ID
- Mode
CNT48
Here you can read out the counter readings of a counter module, select filter options and set various counting modes.
The following counting modes are supported:
- Read on rising edge
- Read on rising edge x2
- Read on rising edge x4
- Period duration
- Frequency measurement
- PWM measurement
Pulse generator
The pulse generator can be used to generate square-wave signals. High and low time as well as the number of pulses can be set here.
PWM Out
In this menu you have the option of testing various PWM frequencies. In addition, the duty cycle can be entered manually for each individual channel.
Temp
The temperature of all connected temperature sensors is displayed here directly in °C.
Graphical display
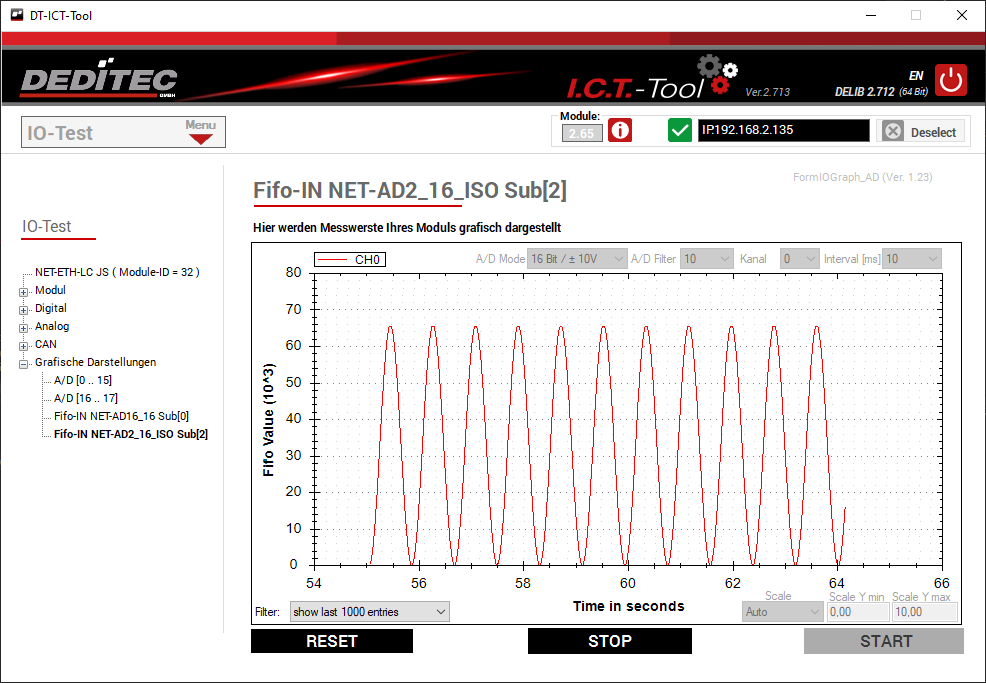
This menu allows a graphical representation of all analog input signals, such as A/D, temperature or FIFO-IN.
Watchdog
This tool can be used to check the configured watchdog parameters for correct function.
I/O – Timeout
You can use the timeout function in the I/O area to simulate a timeout case for your module.
The following is a description of the timeout window
- Read / Write symbol: Flashes to indicate an active connection to the module
- Automatic access: Removing the tick triggers a timeout after the timeout time has expired
- Manual access: Manual retrieval of data from the module
- Timeout status: Shows whether the timeout is active and whether a timeout event has occurred
- Timeout mode: Selection between 3 timeout modes, Normal, Reactivate and Secure
- Timeout duration: The time after which the timeout should be triggered is set here
- Activate / deactivate: Activates or deactivates the timeout function
Access times tests
You can test the access times for the module here. The following access time tests can be performed:
- Register – Read/Write/Write + Readback
- Digital I/O – Read/Write/Write + Readback
- Analog I/O – Read/Write/Write + Readback
Access times tests
This test can be used to determine the access times to the module. The test values are read and written in 8, 16, 32, or 64-bit commands.
Access times Register
The following example checks the register accesses to an Ethernet module. The average access time here is 0.5 ms.
Access times Analog I/O
In the following example, the access times to an Ethernet module with analog I/Os are checked. The average access time here is 0.6 ms.
Access times Digital I/O
In the following example, the access times to an Ethernet module with digital I/Os are checked. The average access time here is 0.6 ms.
Cable feedback tests
For this test, the digital or analog outputs of the module are connected to the corresponding digital or analog inputs of the module via cable. The feedback test now checks whether the output and input values match.
Cable return test
The cable return test can be used to check the function of all digital and analog inputs and outputs (I/Os) of a module. To do this, inputs and outputs are wired together externally on a 1:1 basis. The test software analyzes whether the output signals arrive correctly at the inputs, thereby identifying wiring errors or hardware defects.
Analog test
In analog test mode, the D/A converter outputs defined test voltages, which are then read in by the A/D converter and compared with the target values. The software counts the number of test runs and automatically documents any deviations.
Digital test
In the digital test, the switching states of the relay or MOSFET outputs are fed back externally to the optocoupler inputs. Here, too, the software counts and compares the number of cycles and automatically detects transmission errors or deviations.
A/D ripple
The ripple test displays the residual ripple of the individual A/D inputs.
A/D quality measurements
The quality of an A/D measurement is influenced by various factors and can be affected by external interference. A reliable method for checking measurement quality is to measure a stable battery voltage. Our diagnostic tools can be used to determine the residual ripple and noise behavior.
A/D ripple
The A/D ripple test can be used to measure the residual ripple of the individual A/D inputs and check for interference signals such as mains hum or voltage instabilities.
A/D noise
The noise behavior of each A/D channel can be displayed graphically using A/D noise measurement. Additional filter stages with averaging can be used to smooth and improve the measurement signal.
FIFO In/Out
The software FIFO test can be used to specifically test the integrated FIFO buffering of our digital and analog NET I/O modules. Depending on whether it is an input or output module, data is read from the submodule FIFO or written to the submodule FIFO.
FIFO settings
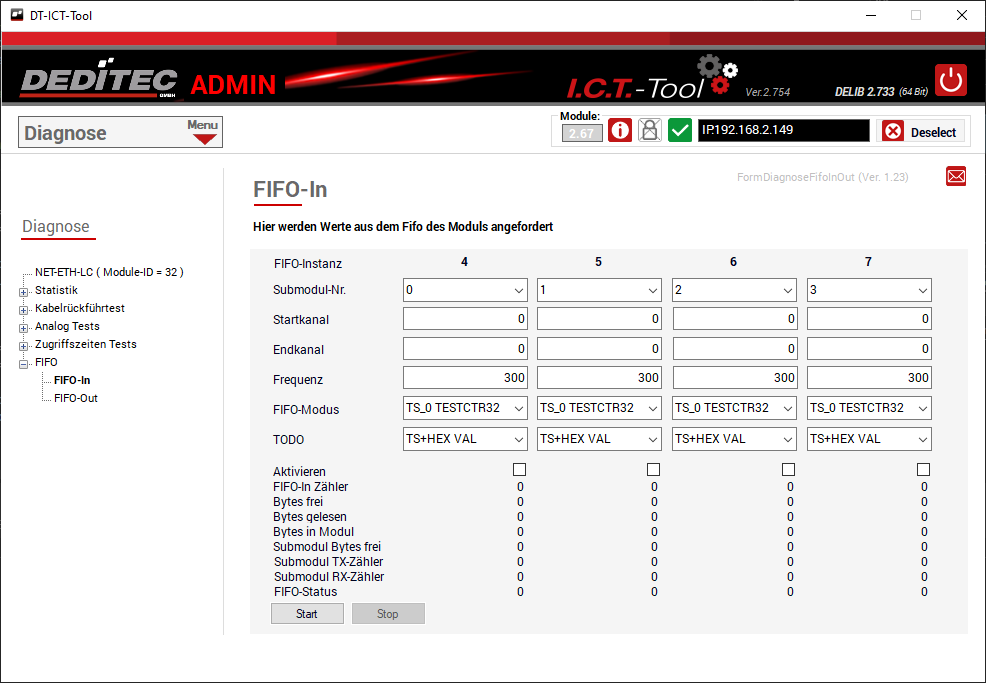
The submodule number can be used to specify which module is to be tested. The start and end channels can also be used to transmit several channels simultaneously. In addition, the transmission frequency can be set and the desired FIFO mode selected – for example, for the use of test values or the actual measured values of the module.
All important information at a glance
During program execution, key information such as the size of the data packets, free and occupied bytes in the FIFO buffer, the number of data packets sent or received, and the current FIFO status are clearly displayed.
D/A output test
The D/A output test enables targeted testing of each individual D/A channel of a module. A freely selectable test voltage can be output directly. Currently, simple square wave signals with configurable high and low times are available. The signals can be monitored simultaneously with an oscilloscope. This function is also ideal for long-term tests. The test software detects DELIB errors and logs them automatically.
Mustertext
Mustertext
DO 4* value + wait
In this test, adjustable 16-bit values are written to the digital outputs of the module.
The values are sent to the module using the DapiDOSet16 command. The start channel is always channel 0.
You can set different wait times between the individual calls.
The test is intended for testing the functionality of the module.
Mustertext
Mustertext
Modbus I/O test
In the diagnostics section of the ICT-Tool, you can test the module’s digital and analog inputs and outputs directly via Modbus TCP. Register addresses as well as transfer and return values are displayed in a debug panel, allowing you to quickly diagnose problems with the D/A converter, for example. A complete overview of all register addresses and examples can be found in the Modbus manual at the following link:
To benefit from the latest functions and prevent errors, we recommend that you always keep your DEDITEC product up to date.
Flash Files
Downloading the firmware flash file package via the ICT tool
- Go to Flash Files in the “Firmware update” menu
- Click on the download button to start the download.
- Administration rights are required for the automatic unpacking of the flash files. If these rights are not available, the files are downloaded to the download area of your PC and must be extracted manually to the installation directory.
\DEDITEC\DELIB\programs\flash_files
Downloading the firmware flash file package via the DEDITEC homepage
- Download the required firmware flash file package from our homepage: Downloads -> Software -> Firmware
- Extract the files to the following installation path: ..\DEDITEC\DELIB\programs\flash_files
Flash modules
In the “Firmware update” menu, select the module you want to update and then click on the “Flash modules” or “Flash submodules” button.
The firmware is now updated and the module is then restarted automatically.
Information on the firmware flasher
The following information is displayed in the firmware flasher:
- Last FW: Displays the last firmware version
- Current FW: Displays the currently installed firmware version
- Newest FW: Displays the latest firmware version
- Log: Displays status or error messages during the flash process
In den folgenden Kapitel, würden wir Ihnen unsere neue All-In-One-Software gerne genauer vorstellen.
General
Here you can make general configurations to the ICT tool.
The following changes can be made:
- Language – setting between German and English possible
Updates
Here you can search for available DELIB or firmware updates.
- Automatic update search at program start
- Search for DELIB updates
- Search for firmware updates
Error log
Here you can make settings for the deditec_debug.log. This is saved under the path C:\Users\?USER?\AppData\Local\DEDITEC.
The following settings can be made:
- Enable writing to the debug.log
- Activate log notifications
- Activate automatic deletion of the debug.log
- Setting after how many days the debug.log should be deleted
- Set the maximum size of the debug.log
DELIB – DebugView – Global
Settings can be made here for the information that is to be displayed with the DebugView.
- Activate debug output
- Activate display of errors
DELIB – DebugView – Details
More detailed settings can be made here for the information to be displayed with the DebugView.
Configuration of our modules via the Ethernet / WiFi and USB interface
Depending on the product series, different interfaces are available for configuration with the control PC.
(Dynamic IP)
(Static IP)
In order to be able to address the DEDITEC product via Ethernet, it must be provided with the corresponding network settings. The following options are available for configuration:
- USB
- Ethernet / Dynamic IP
- Ethernet / Static IP
- Web interface
- WiFi
Connect the DEDITEC module to your PC via USB cable. Thanks to the Plug & Play function and the DELIB driver library, our modules are automatically recognized by your computer’s operating system. You can now access the module with our ICT-Tool and make the network settings in the configuration menu.
In DHCP mode, the DEDITEC module is automatically assigned a free IP address and the appropriate network settings by a DHCP server. The following options are available for activating DHCP mode:
- Activation via DIP switch
- Activation via the network search function in the “Edit / Add menu” of the ICT-Tool
- Activation via the “Module configuration menu” of the ICT-Tool
- Activation via the web interface of the module
DHCP mode can be activated on all DEDITEC modules with DIP switch 1.
In the “Edit / Add menu” of the ICT-Tool, you can scan the network for connected DEDITEC modules. Any modules found are then displayed in a list view where they can be configured and saved.
Click on the “Edit” button in the line of the desired module.
You can now make the desired network configuration in the following window and save it in the module using the “Save / Test” button.
To access the module’s configuration menu, the module must first be integrated into the ICT-Tool.
As the factory IP settings of the module often do not match the network settings of the customer’s PC, the following options are available to help you change them:
- Integration via the USB interface
- Integration via DHCP with DIP switch 1
- Direct connection to the PC * IP factory setting via DIP switch
- Integration via WiFi
Integration via the USB interface (only if available)
Connect the DEDITEC module to your PC via USB cable. Thanks to the Plug & Play function and the DELIB driver library, our modules are automatically recognized by your computer’s operating system. You can now select the module in the main menu of the ICT-Tool and make the network settings in the configuration menu.
Integration via DHCP using DIP switch 1
Set DIP switch 1 on your module to “ON” and switch the module on.
The module now starts in DHCP mode and can be added or selected as a module in the ICT-Tool. You can now make the network settings in the configuration menu. Then reset DIP switch 1 again.
Integration via the IP factory settings with DIP switch 3 and crossover cable
Connect the DEDITEC module directly to your PC using a crossover cable. Set the module’s DIP switch 3 to “ON” and switch the module on. The module now starts with the factory IP address 192.168.1.1. Temporarily set your PC to the same 192.168.1.x network and then add the DEDITEC module in the ICT-Tool.
You can now change the network settings of the module in the configuration menu. DIP switch 3 and the PC IP settings are then reset.
Integration via WiFi (only for WEU series modules)
By pressing the CFG button on the DEDITEC module, you activate the WPS function to automatically connect to the WLAN router of your network (see “WiFi” tab). After a successful connection, the module can be called up in the ICT-Tool via the board name stored in the router – e.g. “boardname.fritz.box” – and can be added as a new module. You can then make the network settings in the configuration menu. For support, contact your system administrator if necessary.
The module is now set to DHCP on the software side.
Central network settings, such as IP configuration or DHCP activation, can be made via the module’s web interface.
To call up the web interface of the module, start your Internet browser and enter the IP address of the module in the URL line. -> For more details, see the “Web interface” tab
To integrate the module into an existing network, it can be permanently assigned a fixed IP address. The following options are available for configuring the module’s network settings:
- Configuration via the network search function in the “Edit / Add menu” of the ICT-Tool
- Configuration via the “Module configuration menu” of the ICT-Tool
- Configuration via the module’s web interface
In the “Edit / Add menu” of the ICT-Tool, you can scan the network for connected DEDITEC modules. Any modules found are then displayed in a list view where they can be configured and saved.
Click on the “Edit” button in the line of the desired module.
You can now make the desired network configuration in the following window and save it in the module using the “Save / Test” button.
To access the module’s configuration menu, the module must first be integrated into the ICT-Tool.
As the factory IP settings of the module often do not match the network settings of the customer’s PC, the following options are available to help you change them:
- Integration via the USB interface
- Integration via DHCP with DIP switch 1
- Direct connection to the PC * IP factory setting via DIP switch
- Integration via WiFi
Integration via the USB interface (only if available)
Connect the DEDITEC module to your PC via USB cable. Thanks to the Plug & Play function and the DELIB driver library, our modules are automatically recognized by your computer’s operating system. You can now select the module in the main menu of the ICT-Tool and make the network settings in the configuration menu.
Integration via DHCP using DIP switch 1
Set DIP switch 1 on your module to “ON” and switch the module on.
The module now starts in DHCP mode and can be added or selected as a module in the ICT-Tool. You can now make the network settings in the configuration menu. Then reset DIP switch 1 again.
Integration via the IP factory settings with DIP switch 3 and crossover cable
Connect the DEDITEC module directly to your PC using a crossover cable. Set the module’s DIP switch 3 to “ON” and switch the module on. The module now starts with the factory IP address 192.168.1.1. Temporarily set your PC to the same 192.168.1.x network and then add the DEDITEC module in the ICT-Tool.
You can now change the network settings of the module in the configuration menu. DIP switch 3 and the PC IP settings are then reset.
Integration via WiFi (only for WEU series modules)
By pressing the CFG button on the DEDITEC module, you activate the WPS function to automatically connect to the WLAN router of your network (see “WiFi” tab). After a successful connection, the module can be called up in the ICT-Tool via the board name stored in the router – e.g. “boardname.fritz.box” – and can be added as a new module. You can then make the network settings in the configuration menu. For support, contact your system administrator if necessary.
The module is now set to DHCP on the software side.
Central network settings, such as IP configuration or DHCP activation, can be made via the module’s web interface.
To call up the web interface of the module, start your Internet browser and enter the IP address of the module in the URL line. -> For more information, see the “Web interface” tab
All central network settings for the module can be made via the module’s web interface.
Access to the web interface
To call up the web interface of the module, start your Internet browser and enter the IP address of the module in the URL line. The access data is set at the factory as follows:
| IP address: | 192.168.1.1 |
| User name: | admin |
| Password: | admin |
If you do not know the IP address of the module, simply use the network search function in the “Edit / Add Men” of the ICT-Tool or look at the IP address assignment in your router.
You can also find more information on this under the “Static IP” or “Dynamic IP” tabs
All modules in the WEU series have an integrated WiFi interface. The connection to a WiFi network can be established either via the ICT-Tool or by pressing the CFG button on the module. You can then make further network settings in the configuration menu. The following options are available for establishing a WiFi connection:
- Establish WiFi connection via button
- Establish automatic connection via ICT-Tool (WPS)
- Establish manual connection via ICT-Tool
By pressing the CFG button on the DEDITEC module, you activate the WPS function to automatically connect to the WLAN router of your network.
Different modes are activated depending on the duration of operation:
- 3–6 Press and hold for seconds: Activate WiFi
- 7–12 Press and hold for seconds: Start WPS connection
- 13–15 Press and hold for seconds: Deactivate WiFi
A status LED on the module indicates the current mode by flashing.
WPS – Simple connection to the network
WPS (WiFi Protected Setup) makes it particularly easy to connect to a WLAN network – without having to enter a network name or password manually.
This is how the WPS connection works:
- Activate WPS mode on the module (press the CFG button for 7-12 seconds)
- Press the WPS button on the router within 2 minutes*.
- The connection is now established automatically.
* Note:
For this type of connection to work, the router used must support WPS. Otherwise, the WLAN connection must be set up manually via the LAN configuration in the ICT-Tool.
A connection to the router can be established automatically in the WPS tab. To do this, press the “WPS Start” button and activate the WPS function on the router within two minutes. The devices will then connect to each other automatically.
If the router login data is known, a connection can be established in the WiFi configuration tab by entering the user name and password. Please note that WiFi must also be activated.
Configuration of CAN modules
The parameters of the CAN interface can be fully configured via the ICT-Tool. In addition to the baud rate, CAN address and other settings, automatic send and receive packets can also be set up.
Automatic transmission (TX mode)
The Auto-TX mode allows cyclical transmission of data packets, optionally with analog or digital input states to other CAN addresses. Alternatively, a trigger event can also be defined. In this case, a data packet is only sent once a data packet has been received on a certain CAN ID (e.g. CAN sync on ID 0x80).
Automatic receiving (RX mode)
With Auto-RX mode, on the other hand, received data packets are forwarded directly to analog or digital outputs. For example, relay outputs can be set via another CAN bus subscriber.
ICT-Tool
The ICT-Tool can be used to quickly and easily read out or change CAN interface settings.
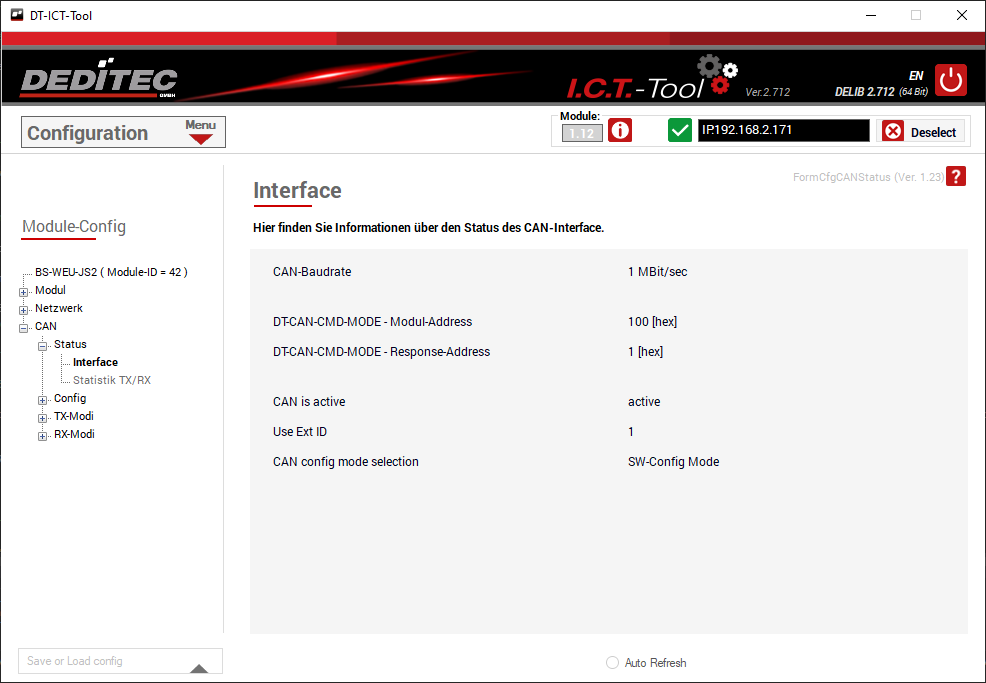
Status interface
Here you can find information about the status of the CAN interface
- Baud rate
- Module address
- Receiving address
- CAN status
- Extended ID
- CAN modus
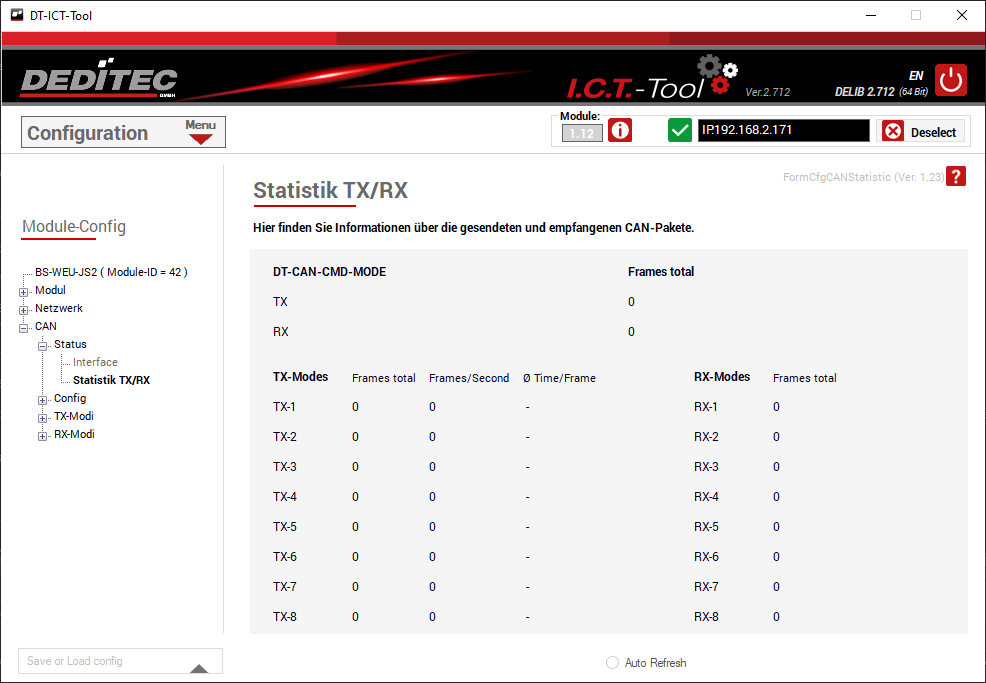
Hier finden Sie Informationen über die TX / RX -Pakete
- Anzahl gesendeter / empfangener Pakete
- TX / RX – Pakete pro Sekunde
- Durchschnitt gesendeter / empfangener Pakete
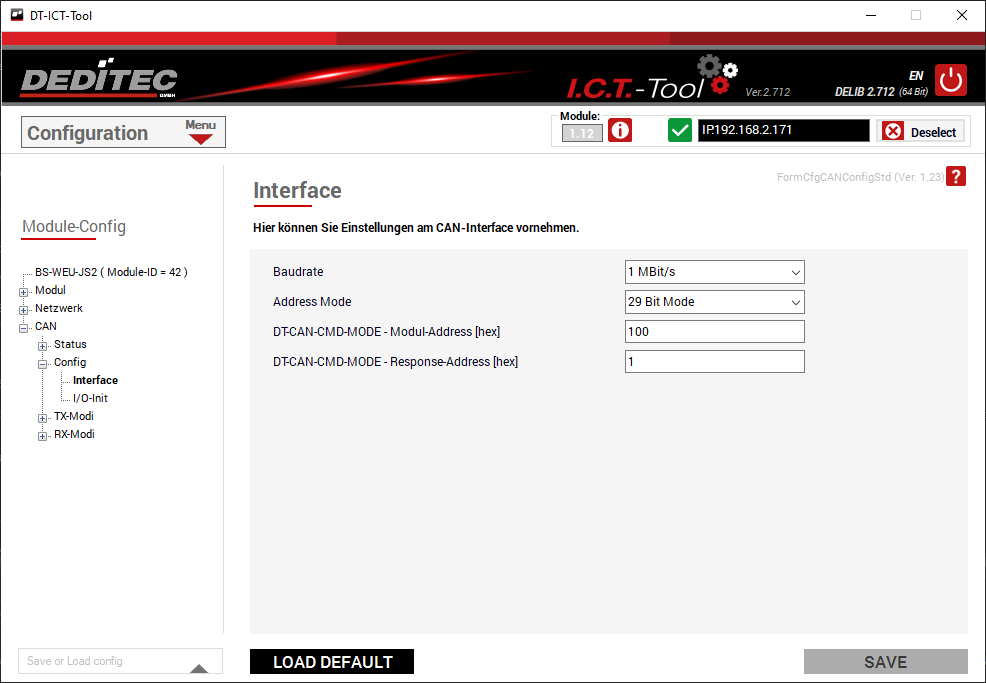
Settings can be made on the CAN interface here.
- Baud rate
- Adress Bit-mode
- Module address
- Receiver address
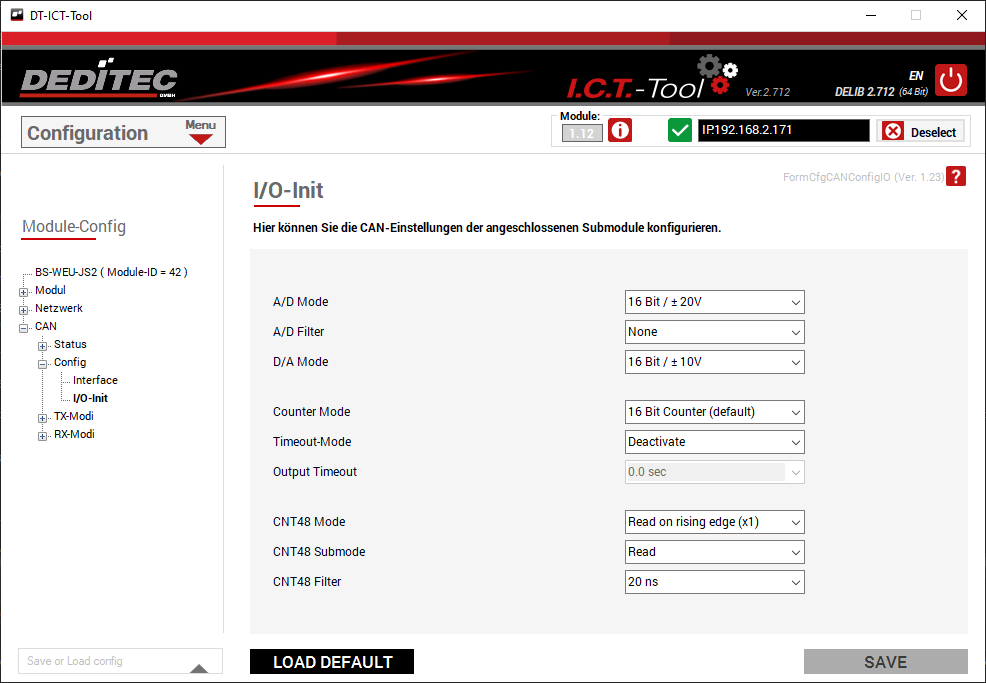
Here you can configure the CAN settings of the connected submodules.
- A/D mode
- A/D filter
- D/A mode
- Counter mode
- Timeout
- CNT48 mode
- CNT48 submode
- CNT48 filter
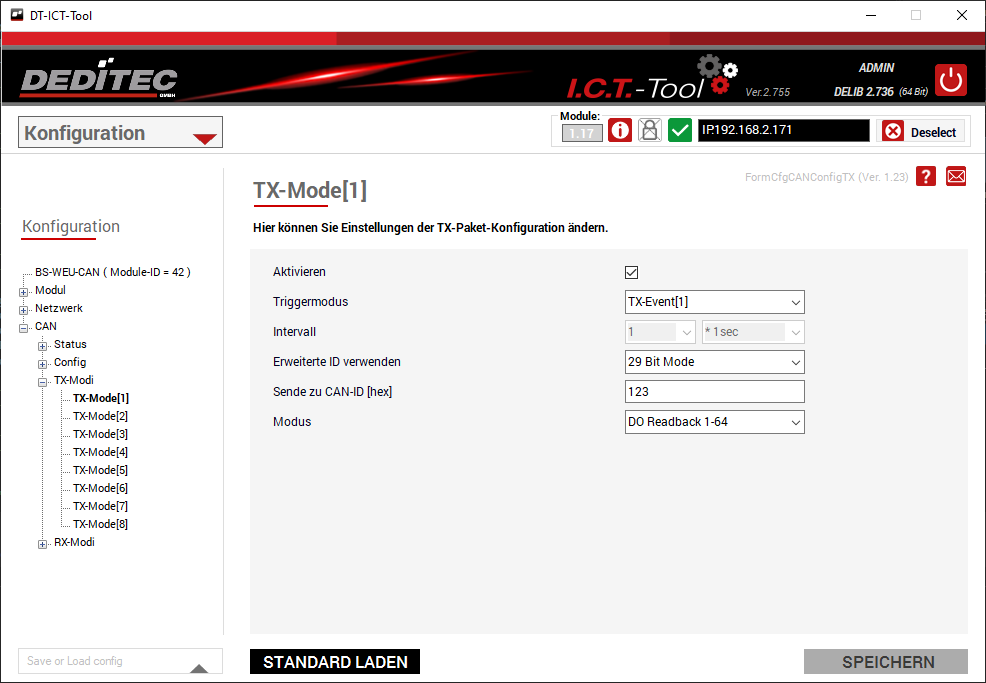
Here you can make settings to the TX package configuration.
- activate / deactivate
- Trigger mode
- Interval
- Use extended ID
- Send to CAN-ID
- TX mode
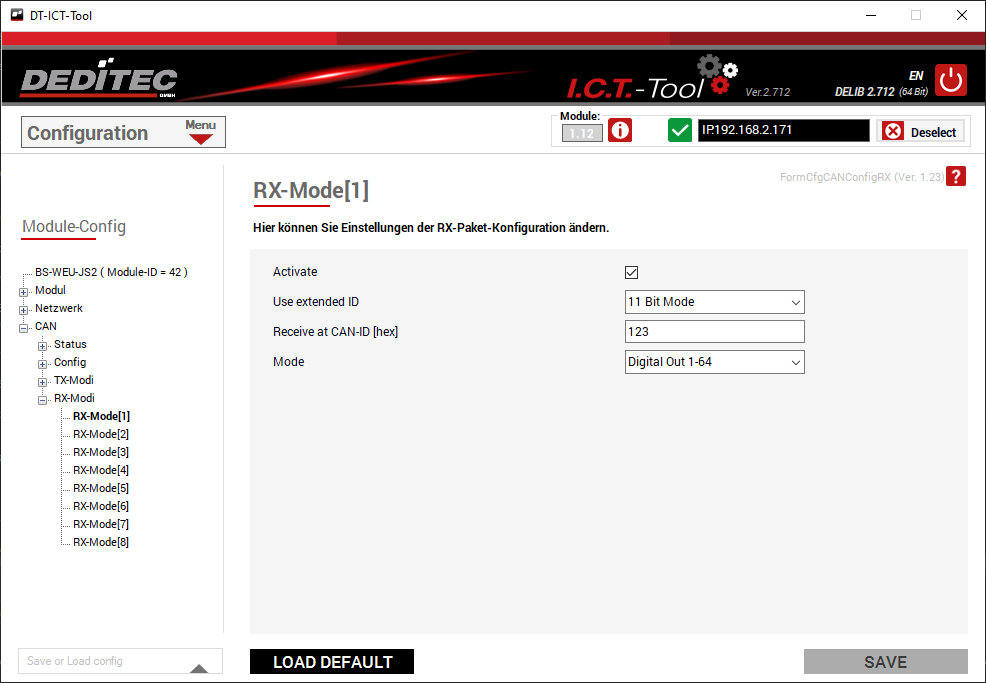
You can make settings to the RX package configuration here.
- activate / deactivate
- Use extended ID
- Receive from CAN-ID
- RX mode
You can find more details on control and some programming examples in the programming section.
Configuration of our serial modules (RS-232 / RS-485)
To configure the serial interface, the module must be connected to the PC either via the Ethernet interface or USB interface.
The module can then be accessed and configured in the ICT tool.
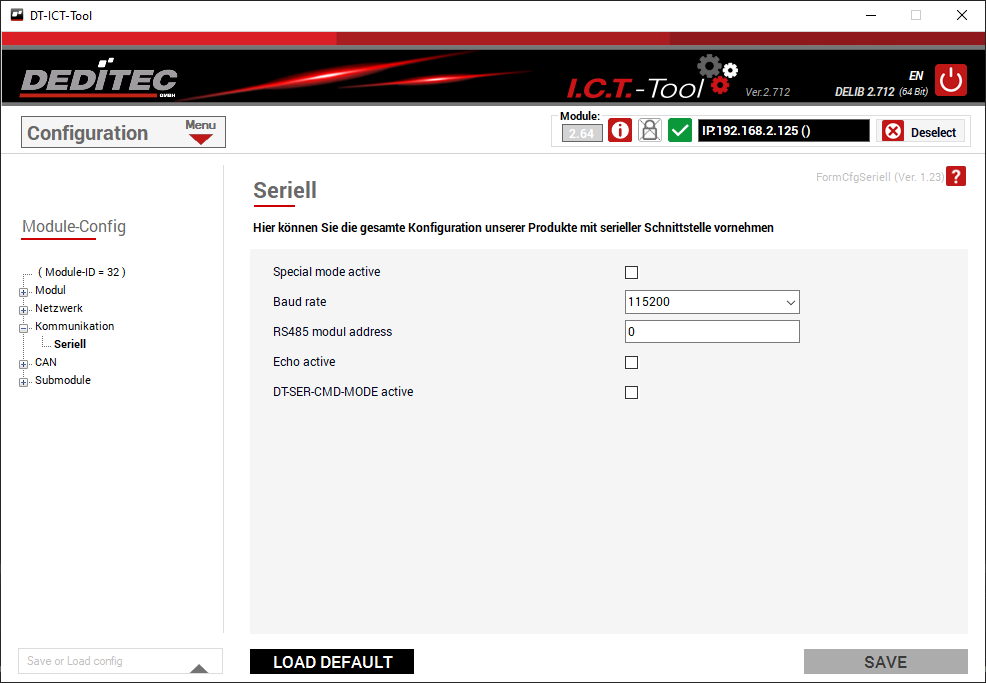
The following parameters can be set:
- Preferred mode (115k baud, module address = deactivated, echo = off)
- Baud rate
- Module address (only for RS-485)
- Echo active on/off
- Text mode / Register mode
Changing the interface standard
Switch between RS-232 and RS-485 (applies only to NET and RO series)
The modules are configured for RS-232 operation as standard when delivered. The module can be switched to RS-485 operation by changing the jumper positions. Further information on this can be found in the manual for the respective product.
Control of Ethernet modules via Modbus TCP protocol
Modbus TCP is a protocol based on TCP/IP that is used for communication between different devices. It allows data to be read and written via so-called registers and bits. Standardized function codes are used for this purpose, such as:
General register allocation
| Modbus register (dez) |
Data type | Access | Data size (Bit) |
Description |
| 0 ... 9999 | Coil | write / read | 1 | Writing and reading back digital outputs |
| 10000 ... 19999 | Discrete Inputs | read | 1 | Read digital inputs |
| 30000 ... 39999 | Input Register | read | 16 | Read holder register |
| 40000 ... 49999 | Holding Register | write / read | 16 | Write and read back registers |
Control of Ethernet modules via Modbus TCP
Our modules can be controlled via the Modbus register protocol for quick and easy integration. This protocol allows you to conveniently read and write values, switch digital outputs, or query inputs. The complete protocol is available for download.
Example:
// Writes the digital outputs of channels 1-16
MASTER.WriteMultipleRegisters(SLAVE_ID, 0x0420, 0x03);
// Reads the values from channels 1-16
registerValue = MASTER.ReadHoldingRegisters(SLAVE_ID, 0x0420, NUMREGISTERS);
Configuration of our Modbus TCP modules
The Ethernet module is configured as follows at the factory:
Modbus active = YES
Modbus IP address = IP address of the module
Modbus port = 502 (standard Modbus port)
If you would like to use your own settings or deactivate the Modbus function, please use the configuration menu of our ICT-Tool.
Changing the parameters in the ICT-Tool
1. Setting/changing the IP address:
The IP address for Modbus TCP and TCP-IP is always identical.
Detailed instructions on how to change the IP address can be found at the following link:
2. Deactivate the Modbus function in the module:
If you want to deactivate the Modbus function, navigate to the “Modbus TCP” submenu, uncheck the “Enable” box, and then save your settings.
3. Port configuration
Modbus TCP communication takes place on port 502 by default. Alternatively, any port between 100 and 49151 can be set.

Modbus I/O test
In the diagnostics section of the ICT-Tool, you can test the module's digital and analog inputs and outputs directly via Modbus TCP. Register addresses as well as transfer and return values are displayed in a debug panel, allowing you to quickly diagnose problems with the D/A converter, for example. A complete overview of all register addresses and examples can be found in the Modbus manual at the following link:

M2M
Machine to Machine
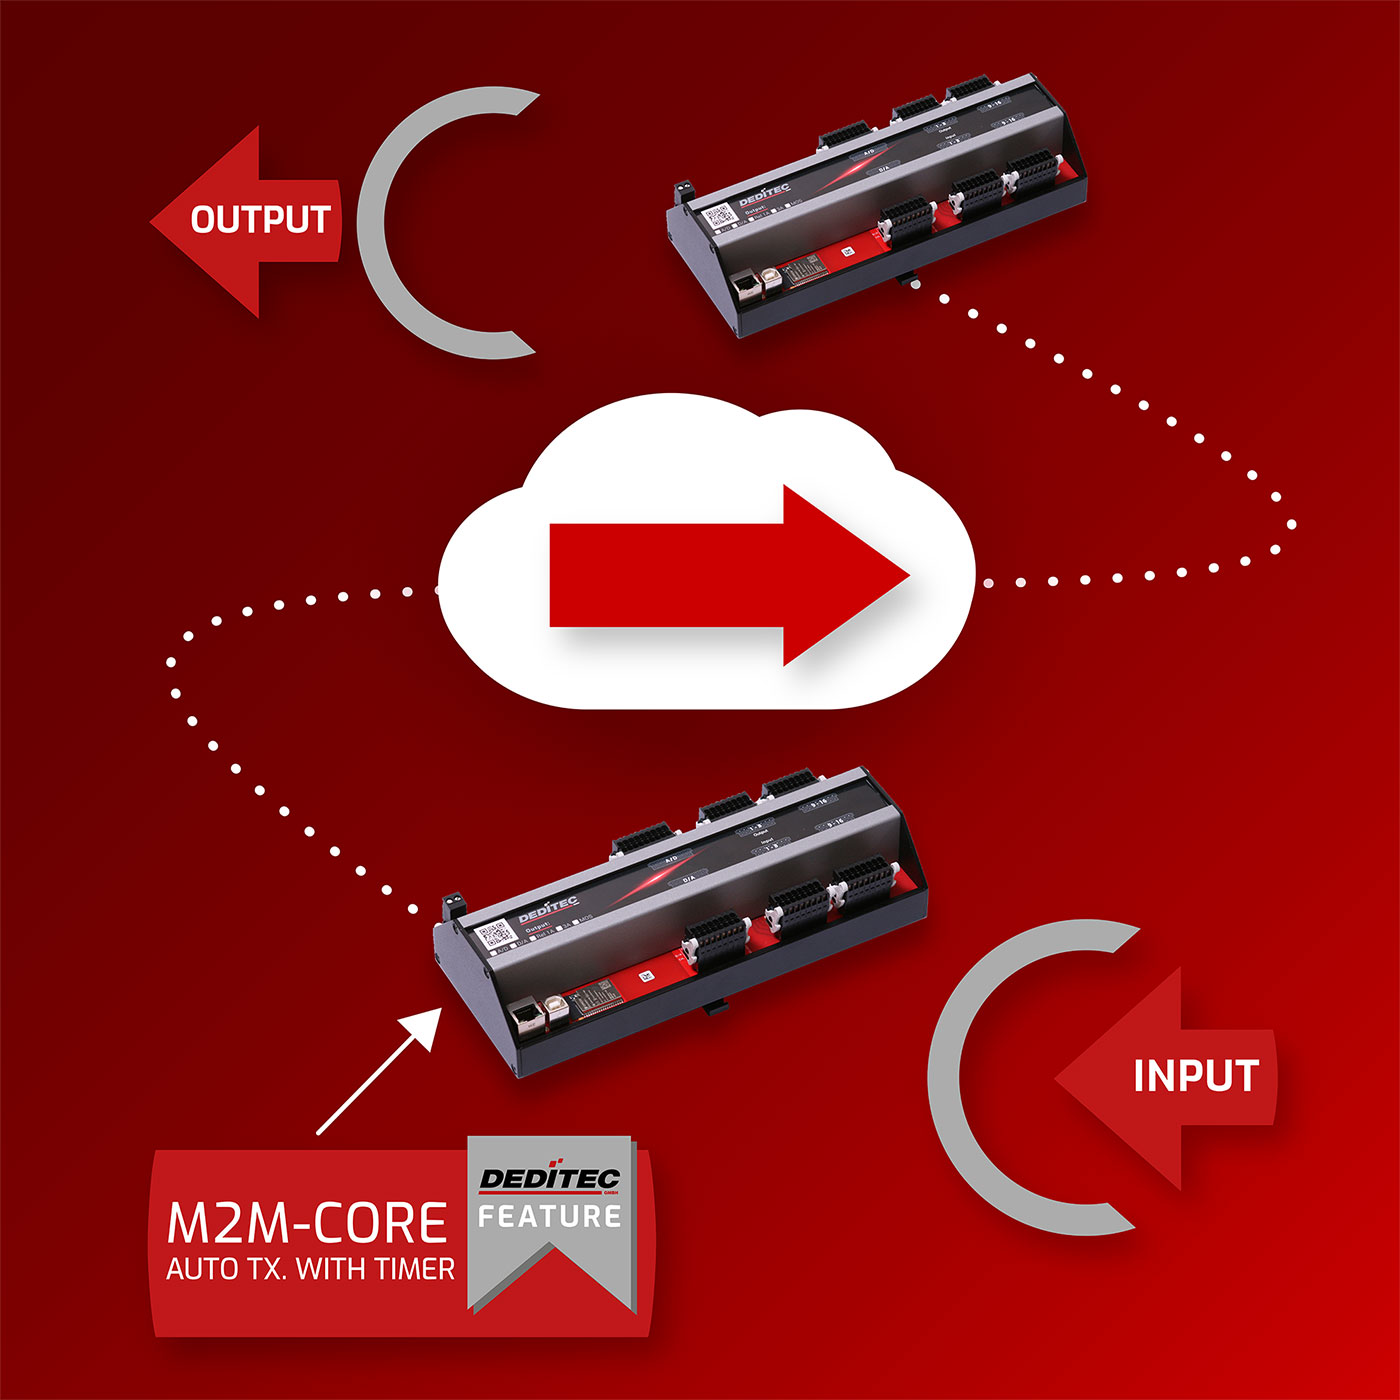
M2M is the abbreviation for “machine-to-machine” and enables automatic data transmission between two or more devices. This means that analog or digital input signals from a transmitter module can be automatically transmitted to a receiver module, where they are immediately output again.
Data exchange without a control PC
The modules communicate directly at device level and therefore do not require any additional user software. The one-off configuration of the transmitter module can be carried out very easily using our ICT-Tool. All settings remain permanently stored in the module memory, even in the event of a power failure. After a restart, the module automatically switches back to M2M operation.
M2M Ethernet or M2M CAN
With our DEDITEC products, we differentiate between M2M Ethernet and M2M CAN. We also refer to the latter as CAN-TX/RX mode. Both M2M methods are supported by most of our modules with Ethernet or CAN interface.
M2M-Ethernet
To be able to use M2M-Ethernet, the transmitter module must always be equipped with our M2M feature, whereas the receiver module can be any DEDITEC product with an Ethernet interface.
A maximum of 4 receiver modules (destinations) can currently be configured and up to 8 actions defined.
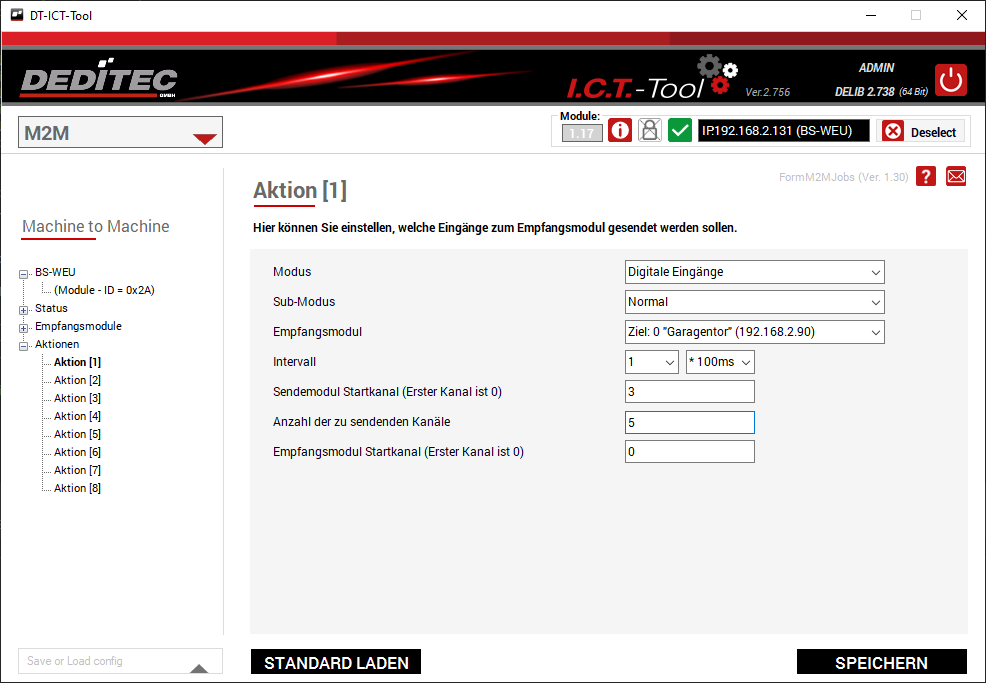
Definition of the receiver module
- Designation/name of the module
- Network configuration of the module
- Timeout time
- Encryption type and password
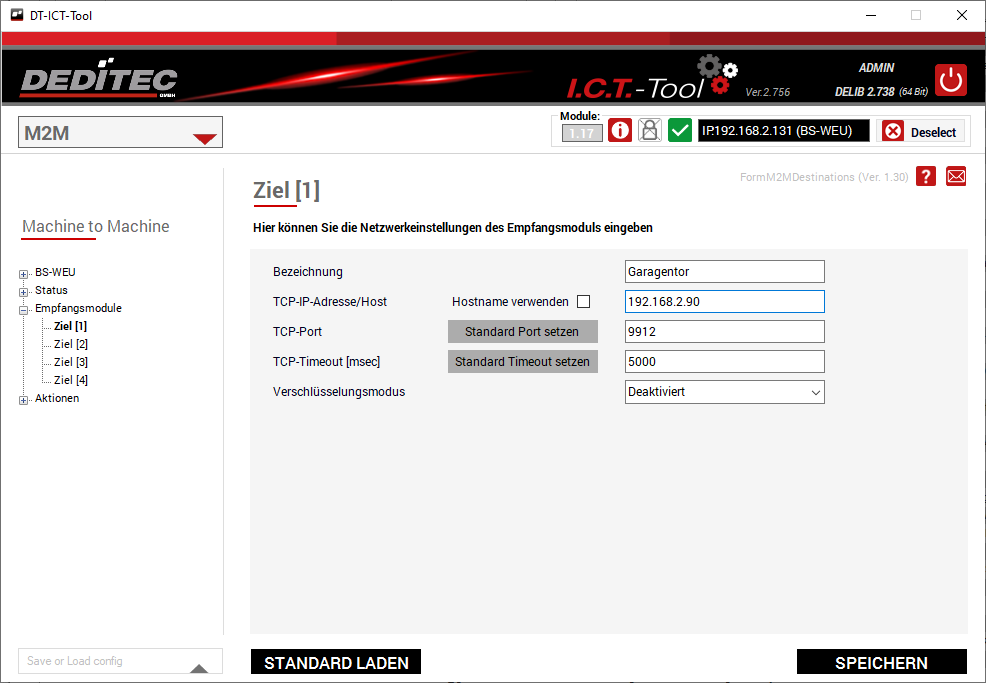
Definition of actions
These actions are used to define which analog or digital inputs are to be transmitted to a receiver module.
The following parameters can be defined in an action:
- Which data should be sent (digital or analog)
- To which receiver module (destination) should be sent
- The interval with which the operations are to be performed
- Start channel of the transmitter module
- Number of input channels to be transmitted
- Start channel of the receiver module
In the image on the right, DI data is sent every 100ms from channel 3(CH Start) to channel 8 ((CH Start) + (CH Count)) to channels 0-5 of the target module.
M2M-CAN
All DEDITEC products with a CAN interface are equipped with the M2M-CAN feature. The “Auto TX/RX mode” can be set in the ICT-Tool via the configuration menu. Depending on the product type, 8(4) TX and 8(4) RX modes can be defined.
"TX modes" submenu
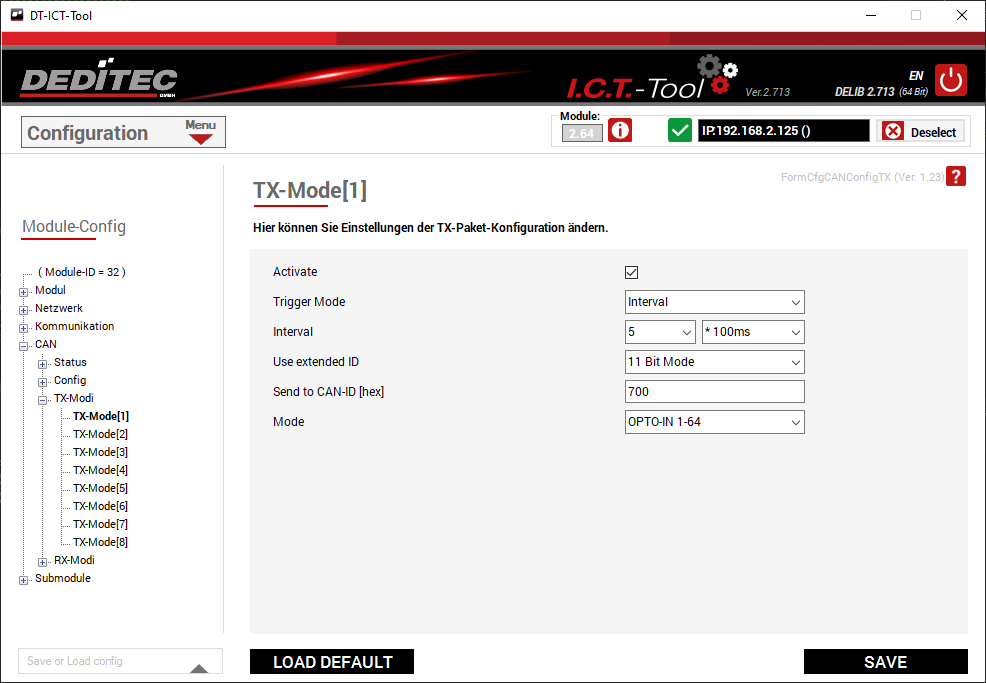
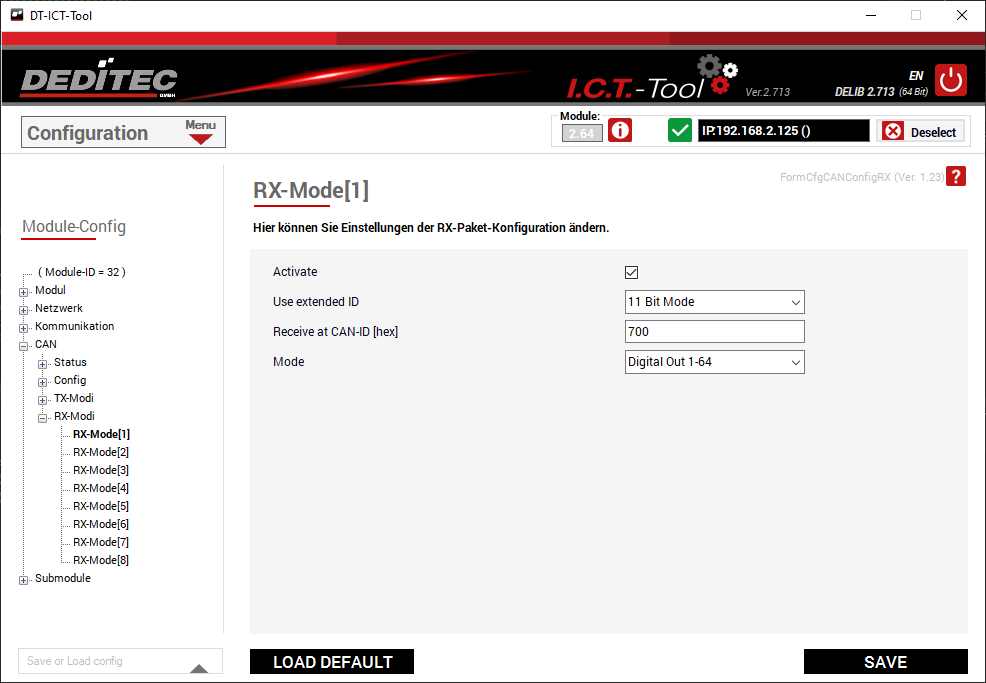
The pictures on the right show an example configuration for a transmitter module (TX mode) and a corresponding receiver module (RX mode).
The TX mode on the transmitter module sends the logical states of inputs 1-64 to CAN ID 0x700 every 500ms.
The RX mode on the receiver module receives data packets on CAN ID 0x700 and outputs these values to outputs 1-64.
Software FIFO
Data processing in real time
In order to be able to process data streams constantly and at short intervals, external interference factors such as network utilization or large spatial distances must be avoided. As this is often not possible in practice, it is necessary to record the data first and store it temporarily in a buffer.
In our NET series modules, we have therefore integrated a software FIFO ("First in-First out"), which stores the required data directly on the module and then processes it independently at a defined time interval. This happens both for incoming data (FIFO-IN) and for outgoing data (FIFO-OUT). The FIFO buffer significantly improves the processes in our measurement procedures and reduces network utilization.
All the advantages at a glance:
- Analog and digital values can be read out at very short intervals (milliseconds)
- Exact readout of values in a self-defined time interval possible
- The FIFO does not consume more traffic at higher utilization via the Ethernet interface
Testing and programming
You can use our ICT tool to test and diagnose the FIFO-IN and FIFO-OUT with digital and analog I/Os.
You will also find support and help for correct programming in the source code of our FIFO sample programs.
General information on Event-Control
In den folgenden Kapitel, würden wir Ihnen unsere neue All-In-One-Software gerne genauer vorstellen.
To make our modules even more customer-friendly and flexible and to make it easier for you to enter the world of automated control technology, we have implemented Event-Control as a new feature in our products. This function can be used to implement small control tasks that are stored in the module. These control tasks are configured as events and actions and then executed automatically according to the “if-then” principle.
Configuration in the ICT-Tool
The ICT-Tool can be used to configure and monitor 16 events and 16 actions.
Processing in the module
The events stored in the module are automatically monitored and processed by the CPU in the module after the module is started. As soon as the set condition (“event”) is fulfilled, the corresponding action is executed. This automatism in the module makes an additional control PC with associated user software superfluous.
Functions
The following actions, among others, can be combined with the Event-Control:
- Monitoring the analog and digital inputs (A/D, DI)
- Setting switching thresholds for analog inputs
- Switching the module outputs (relay, MOSFET, D/A)
- Sending CAN packages
We are constantly expanding the range of promotional options. We are also happy to implement your special customer requirements on request.
Modulauswahl
Hier können Sie Ihre Module mit einem Klick auf das „+“ Symbol ins ICT-Tool einbinden, um diese anschließend konfigurieren oder testen zu können.
Module series that support this function:
- BS-USB2 series
- BS-WEU series
- NET series
- UC series
- CAN-Box series
Module series that do not support this function:
- Starter series
- RO series
- COS series
ICT Treeview
Im Treeview auf der linken Seite des Programmfensters, sehen Sie die jeweiligen Formen, die von Ihrem Modul unterstützt werden.
Mit einem Klick können Sie sich diese Form dann im rechten Teil des Programmes anzeigen lassen und mögliche Konfigurationen oder Tests durchführen.
In den folgenden Kapitel, würden wir Ihnen unsere neue All-In-One-Software gerne genauer vorstellen.
With the Event-Control module, you can react flexibly and automatically to external signals – directly on the I/O module, without a PC or additional controller.
How does it work?
The system registers external events, such as the switching of an input or the triggering of a sensor, and then executes predefined actions. These actions can be simple tasks such as switching on a relay or sending a CAN message.
The advantages:
-
Independent processing – Control takes place directly on the module, independently of the host system.
-
Flexibly customizable – you can link any inputs and outputs together.
-
Complex logic possible – Thanks to logical operators such as AND, OR or NOT, even more sophisticated controls can be implemented.
-
Simple configuration – events and actions are conveniently defined via our ICT-Tool and transferred to the module without any programming knowledge.
Example:
A digital input detects the opening of a door. The system then automatically switches on a light without a PC being involved.
Modulauswahl
Hier können Sie Ihre Module mit einem Klick auf das „+“ Symbol ins ICT-Tool einbinden, um diese anschließend konfigurieren oder testen zu können.
Modulserien, die von dieser Funktion unterstützt werden:
- BS-USB2-Serie
- BS-WEU-Serie
- NET-Serie
- UC-Serie
- CAN-Box
Modulserien, die von dieser Funktion nicht unterstützt werden:
- Starter-Serie
- RO-Serie
- COS-Serie
ICT Treeview
Im Treeview auf der linken Seite des Programmfensters, sehen Sie die jeweiligen Formen, die von Ihrem Modul unterstützt werden.
Mit einem Klick können Sie sich diese Form dann im rechten Teil des Programmes anzeigen lassen und mögliche Konfigurationen oder Tests durchführen.
Our ICT-Tool in the “Statistics” section provides a quick overview of all current campaigns and events.
Eine mini SPS
Um unsere Module noch kundenfreundlicher und flexibler zu gestalten und Ihnen den Einstieg in die Welt der automatisierten Steuer- und Regelungstechnik zu erleichtern, haben wir als neues Feature das sog. Event-Control in unsere Produkte implementiert. Mit dieser Funktion lassen sich kleine Steueraufgaben in das Modul speichern, die anschließend nach dem „Wenn-Dann“ Prinzip automatisch Aktionen ausführen.
The following information can be taken from the statistics:
- Executed event no.
- Event mode
- Interval
- Number of events executed
- Number of the executed action
- Number of actions performed
Modulserien, die von dieser Funktion unterstützt werden:
- BS-USB2-Serie
- BS-WEU-Serie
- NET-Serie
- UC-Serie
- CAN-Box
Modulserien, die von dieser Funktion nicht unterstützt werden:
- Starter-Serie
- RO-Serie
- COS-Serie
ICT Treeview
Im Treeview auf der linken Seite des Programmfensters, sehen Sie die jeweiligen Formen, die von Ihrem Modul unterstützt werden.
Mit einem Klick können Sie sich diese Form dann im rechten Teil des Programmes anzeigen lassen und mögliche Konfigurationen oder Tests durchführen.
An event is used to execute a specific action as soon as a condition is met.
A time period can also be specified for how long the condition must be fulfilled in order to execute an action.
These settings are saved directly in the Module-Configuration-Memory of the module.
Example: Voltages can be automatically output via the D/A converter or relays can be switched when a previously defined switching threshold is reached at the A/D inputs or a signal is detected at a digital input.
Depending on the features of your product, you can choose from different modes:
“DI” / “DI flip-flop” / “DO readback”
DI: High or low signal of a digital input.
Flip-Flop: If the status of the digital input changes, the flip-flop of the channel is set and then reset again.
DO-Readback: The status of the output channel is read out.
The following settings can be made:
- Number of the channel to be monitored
- Condition of the channel status (on = 1 / off = 0)
- Minimum time to wait until the action is triggered
- Number of the action to be executed (this is configured in the Action area)
“A/D”
The voltage currently present at the analog input is read out.
The following settings can be made:
- Number of the channel to be monitored
- A/D mode (selection depends on module)
- Condition that must be fulfilled (value greater than … , value less than … , value in a range)
- Values that must be achieved for the condition
- Minimum time to wait until the action is triggered
- Number of the action to be executed (this is configured in the Action area)
In the “Actions” section of our ICT-Tool, you define which tasks are to be performed automatically as soon as a condition (“event”) is fulfilled.
For example, you can specify that a certain CAN packet should be sent when a certain voltage is measured on an A/D channel or a signal is detected at a digital input.
Depending on the features of your product, you can choose from different modes:
Folgende Informationen können der Statistik entnommen werden:
- Ausgeführte Event-Nr.
- Event-Modus
- Intervall
- Anzahl ausgeführter Events
- Nummer der ausgeführten Aktion
- Anzahl ausgeführter Aktionen
“Set D/A output”
Outputs a voltage or a current at an analog output.
The following settings can be made:
- Number of the channel on which the action is to be executed
- D/A mode (selection depends on module)
- Voltage or current to be output
- Time to wait before executing the action again
“Set DO output”
Switches a digital output on or off.
The following settings can be made:
- Number of the channel to be controlled
- State (0 = off / 1 = on) that is to be set
- Time to wait before executing the action again
“Send CAN package”
The set CAN TX event is triggered. For this function, the trigger mode in the CAN TX package must be set to “TX-EVENT” (see configuration).
The following settings can be made:
- Number of the CAN TX event to be triggered
- Time to wait before executing the action again (prevents a CAN packet from being sent too frequently)
You can find more information on configuring TX mode here:
Control of our CAN modules
Our CAN modules can be controlled in two ways:
1. Auto TX/RX mode for RAW CAN and J1939
2. DELIB Command Mode
1. Auto TX/RX Mode for RAW CAN and J1939
Auto TX/RX mode enables the module to automatically process CAN packets without requiring an additional control PC. Both RAW CAN and J1939 are supported. Configuration is carried out conveniently using the ICT-Tool and does not require any programming knowledge.
CAN Packets via RAW CAN
For a RAW CAN message, you first select whether an 11-bit or 29-bit CAN ID is to be used. The complete CAN ID is then entered directly.
The “Mode” field defines which I/O data is transmitted and how received payload data is processed within the module.
CAN Packets via J1939
To use J1939, select “J1939” in the “CAN Mode” field. Instead of entering a complete 29-bit CAN ID, the individual J1939 address components Prio, PGN, SA and, if applicable, DA are entered.
The ICT-Tool automatically generates the corresponding 29-bit CAN ID from these values. Manual calculation or decomposition of the CAN ID is not required.
When reading an existing configuration, the stored 29-bit CAN ID is automatically split back into Prio, PGN, SA and, if applicable, DA.
Automatic Transmission (TX Mode)
In Auto-TX mode, the DEDITEC module can automatically send CAN messages to other CAN bus participants. Depending on the module configuration, the payload data can include, for example, digital inputs, flip-flop inputs, counter values, or analog input values.
Transmission can take place at a defined time interval, when a specified trigger event occurs, or – depending on the selected mode – as fast as possible.
TX Mode Configuration
The following settings can be configured:
- TX Mode: Enable or disable.
- CAN Mode: RAW CAN with an 11-bit or 29-bit identifier, or J1939.
- CAN ID: Defines the identifier of the CAN message to be transmitted.
- I/O Mode / Data Mapping: Defines how the up to 8 CAN data bytes are assigned module values. In addition to predefined data mappings, CAN Data Msg Composer configurations can also be used.
- Trigger Mode: Defines what triggers the transmission.
- Interval: Defines the transmission interval for time-controlled sending.
Predefined modes are available for frequently used data mappings, for example for four A/D values or 64 digital inputs. For freely composed CAN messages, the CAN Data Msg Composer is also available. It allows the data bytes to be individually combined from different module values.
TX CAN Data Msg Composer
The TX CAN Data Msg Composer allows the content of the CAN message to be transmitted to be configured individually. Four independent TX Composer configurations are available for this purpose. Within a configuration, the selected values are automatically assigned sequentially to the maximum of 8 CAN data bytes.
Configuration Msg Composer
A Composer row consists of the following elements, depending on the selected function:
- Function / Source: Selects the module value to be included in the CAN message. Depending on the module configuration, individual digital inputs (DI_1), groups of 8 digital inputs (DI_8), individual or grouped flip-flop inputs (DI_FF1 / DI_FF8), counter values (DI_CNT), counter values with reset (DI_CNT_W_RESET), A/D values, or a fixed hex value are available.
- Channel / Value: Selects the corresponding channel or channel group. For “VALUE (in hex)”, a fixed hex value is entered directly instead.
- CAN Data 1-8: Selects the data length and, for multi-byte integer values, the byte order. 1, 2, 3, or 4 bytes as well as a 4-byte floating-point value are supported. For 2-, 3-, and 4-byte values, either LSB or MSB byte order can be selected.
- Offset / Multiplier: Optionally enables adjustment of the module value to be transmitted. This function is not required for fixed hex values.
- Byte Assignment: The CAN data bytes occupied by each entry are displayed. The data ranges are automatically arranged consecutively.
The selection of the data length automatically takes the remaining available CAN data bytes into account. As a result, only combinations that fit within the maximum of 8 data bytes of a CAN message are offered. This makes it possible, for example, to combine digital inputs, an A/D value, and a counter value within a single CAN message.
For fixed values, a hex value from 0x00 to 0xFF can be entered directly. This occupies exactly one CAN data byte.

Automatic Reception (RX Mode)
In Auto-RX mode, the DEDITEC module can automatically evaluate received CAN messages and forward the contained data directly to the module outputs. This allows, for example, digital outputs or relays to be switched by another CAN bus participant, or analog output values to be specified.
RX Mode Configuration
The following settings can be configured:
- RX Mode: Enable or disable.
- CAN Mode: RAW CAN with an 11-bit or 29-bit identifier, or J1939.
- CAN ID: Defines which CAN ID is to be evaluated.
- I/O Mode / Data Mapping: Defines how the received CAN data is interpreted and assigned to the module outputs. For individual data formats, RX CAN Data Msg Composer configurations 1 to 4 can be selected.
As with TX mode, different data ranges within a CAN message can also be processed individually when receiving data. The evaluation is then performed entirely within the module based on the selected configuration.
RX CAN Data Msg Composer
The RX CAN Data Msg Composer defines how the maximum of 8 data bytes of a received CAN message are interpreted and processed. Four independent RX Composer configurations are available.
Configuration Msg Composer
A Composer row can contain the following elements:
- CAN Data 1-8: Selects the data range and data format. 1, 2, 3, or 4 bytes as well as a 4-byte floating-point value can be used. For multi-byte integer values, either LSB or MSB byte order can be selected.
- Target: Defines how the selected data range is processed. Depending on the module configuration, “Ignore”, a single digital output (DO1), a group of 8 digital outputs (DO8), or a D/A output are available.
- Channel: Selects the output channel or group of 8 channels to which the received value is applied.
- Offset / Multiplier: Optionally enables adjustment of the received value before further processing.
- Operation: Defines how the received value is evaluated. “None” applies the value without an additional comparison operation. “Invert” is also available for digital outputs. For individual digital outputs (DO1), the comparisons !=, ==, <, <=, >, and >= can also be used, as well as checks for values inside or outside a specified range.
- Value 1 / Value 2: Comparison values for the selected operation. Simple comparisons use “Value 1”; range checks use both “Value 1” and “Value 2”.
“Ignore” can be used to skip a selected data range within the CAN message without generating an output value from it. This also allows messages to be processed in which only specific data bytes are relevant to the module.
Thanks to the flexible assignment of data ranges, optional scaling, and the available comparison operations, received CAN data can be evaluated and processed directly within the module. Additional control software running on a PC is not required for ongoing processing.

2. DELIB command mode
In DELIB command mode, the module's registers are accessed via a CAN protocol developed by DEDITEC. The module expects the CAN messages on a CAN address specified in command mode. Read and write accesses with different data lengths (BYTE, WORD, LONG) are possible. Details on the protocol structure and register assignment can be found in the “Protocols & Register Assignment” manual in the download area.
Control of our RS-232 / RS-485 modules
There are two options available for controlling our RS-232 / RS-485 modules:
1. Register-based via an open protocol
2. Via plain text input via a terminal program
Please note!
We only recommend using the RS-485 interface in conjunction with a microcontroller and your own serial protocol.
1. Control via our open serial protocol
Serial control is register-based. An open communication protocol was created for this purpose, which is used to address the module's registers and thus execute read or write commands. The “Protocols & Register Assignment” manual describes the transmission and reception frames for communicating with RS-232/RS-485 modules.
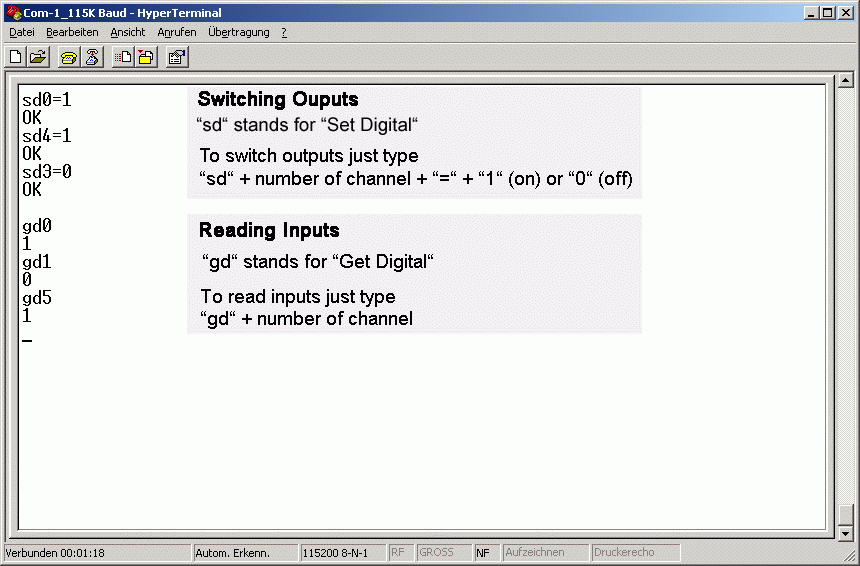
2. Control via plain text using HyperTerminal
The digital inputs and outputs can be controlled or read directly via “plain text” using HyperTerminal. Examples of this can be seen in the adjacent illustration.
Management functions
DapiOpenModule
This function opens a specific module.
Description
This function opens a specific module.
Definition
ULONG DapiOpenModule(ULONG moduleID, ULONG nr);
Parameter
moduleID=Specifies the module to be opened (see delib.h)
nr=Specifies which module is to be opened.
nr=0 -> 1. Module
nr=1 -> 2. Module
Return value
handle=Corresponding handle for the module
handle=0 -> Module was not found
Remark
The handle returned by this function is required to identify the module for all other functions.
Programming example
// Open USB module
handle = DapiOpenModule(RO_USB1, 0);
printf(„handle = %x\n“, handle);
if (handle==0)
{
// USB module was not found
printf(„Module could not be opened\n“);
return;
}
DapiCloseModule
This command closes an open module.
Description
This command closes an open module.
Definition
ULONG DapiCloseModule(ULONG handle);
Parameter
handle=This is the handle of an open module
Return value
None
Programming example
// Close module
DapiCloseModule(handle);
DapiGetDELIBVersion
This function returns the installed DELIB version.
Description
This function returns the installed DELIB version.
Definition
ULONG DapiGetDELIBVersion(ULONG mode, ULONG par);
Parameter
mode=Mode with which the version is read out (must always be 0).
par=This parameter is not defined (must always be 0).
Return value
version=Version number of the installed DELIB version [hex]
Programming example
version = DapiGetDELIBVersion(0, 0);
//With version 1.32 installed
version = 132(hex)
DapiSpecialCMDGetModuleConfig
This function returns the hardware configuration (number of input and output channels) of the module.
Description
This function returns the hardware configuration (number of input and output channels) of the module.
Definition
ULONG DapiSpecialCommand(ULONG handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG, par, 0, 0);
Parameter
handle=This is the handle of an open module
Querying the number of digital input channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DI
Query number of digital input flip-flops
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DI_FF
Query number of digital input counters (16-bit counter)
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DI_COUNTER
Query number of digital input counters (48-bit counter)
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_CNT48
Querying the number of digital output channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DO
Querying the number of digital pulse generator outputs
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_PULSE_GEN
Querying the number of digital PWM outputs
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_PWM_OUT
Querying the number of digital input/output channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DX
Querying the number of analog input channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_AD
Querying the number of analog output channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DA
Query number of temperature channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_TEMP
Query number of stepper channels
par=DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_STEPPER
Return value
Querying the number of digital input channels
return=number of digital input channels
Query number of digital input flip-flops
return=number of digital input flip-flops
Query number of digital input counters (16-bit counter)
return=number of digital input counters (16-bit counter)
Query number of digital input counters (48-bit counter)
return=number of digital input counters (48-bit counter)
Querying the number of digital output channels
return=number of digital output channels
Querying the number of digital pulse generator outputs
return=number of digital pulse generator outputs
Querying the number of digital PWM outputs
return=number of digital PWM outputs
Querying the number of digital input/output channels
return=number of digital input/output channels
Querying the number of analog input channels
return=number of analog input channels
Querying the number of analog output channels
return=number of analog output channels
Query number of temperature channels
return=number of temperature channels
Query number of stepper channels
return=number of stepper channels
Programming example
ret=DapiSpecialCommand(handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG,
DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DI, 0, 0);
//Returns the number of digital input channels
ret=DapiSpecialCommand(handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG,
DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DO, 0, 0);
//Returns the number of digital output channels
ret=DapiSpecialCommand(handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG,
DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DX, 0, 0);
//Returns the number of digital input/output channels
ret=DapiSpecialCommand(handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG,
DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_AD, 0, 0);
//Returns the number of analog input channels
ret=DapiSpecialCommand(handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG,
DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_DA, 0, 0);
//Returns the number of analog output channels
ret=DapiSpecialCommand(handle,
DAPI_SPECIAL_CMD_GET_MODULE_CONFIG,
DAPI_SPECIAL_GET_MODULE_CONFIG_PAR_STEPPER, 0, 0);
//Returns the number of stepper channels
DapiOpenModuleEx
This function specifically opens a module with an Ethernet interface. The parameters IP address, port number and the duration of the timeout can be defined.
Description
This function specifically opens a module with an Ethernet interface. The parameters IP address, port number and the duration of the timeout can be defined. The module is opened independently of the settings made in the DELIB Configuration Utility.
Definition
ULONG DapiOpenModuleEx(ULONG moduleID, ULONG nr, unsigned char* exbuffer, 0);
Parameter
moduleID = Specifies the module to be opened (see delib.h)
nr = Specifies which module (if several) is to be opened.
nr = 0 -> 1. Module
nr = 1 -> 2. Module
exbuffer = Buffer for IP address, port number and duration of the timeout
Return value
handle = Corresponding handle for the module
handle = 0 -> Module was not found
Remark
The handle returned by this function is required to identify the module for all other functions.
This command is supported by all modules with an Ethernet interface.
Programming example
// Open ETH-Module with parameter
DAPI_OPENMODULEEX_STRUCT open_buffer;
strcpy((char*) open_buffer.address, "192.168.1.10");
open_buffer.portno = 0;
open_buffer.timeout = 5000;
handle = DapiOpenModuleEx(RO_ETH, 0, (unsigned char*) &open_buffer, 0);
printf("Module handle = %x\n", handle);
DapiScanAllModulesAvailable
This function can be used to scan all modules connected to the USB bus.
Description
This function can be used to scan all modules connected to the USB bus.
The module ID and module no. of each module found are determined.
Definition
ULONG DapiScanAllModulesAvailable(uint nr)
Parameter
nr = 0: All modules connected to the USB bus are searched for
nr = i: Reading out the individual connected modules
Return value
Indicates the number of modules found.
Programming example
no_of_modules =
DT.Delib.DapiScanAllModulesAvailable(0);
for (i = 1; i <= no_of_modules; i++)
{
ret = DapiScanAllModulesAvailable(i);
moduleID = ret & 0x0000ffff;
moduleNr = (ret >> 16) & 0xff;
}
Register functions
DapiWriteByte
This command executes a direct register write command to the module.
Description
This command executes a direct register write command to the module.
Definition
void DapiWriteByte(ULONG handle, ULONG adress, ULONG value);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
value=Specifies the data value that is written (8-bit)
Return value
None
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Data is written to register 0x10
DapiWriteByte(handle, 0x10, 0xFF);
DapiWriteWord
This command executes a direct register write command to the module.
Description
This command executes a direct register write command to the module.
Definition
void DapiWriteWord(ULONG handle, ULONG adress, ULONG value);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
value=Specifies the data value that is written (16-bit)
Return value
None
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Data is written to register 0x10
DapiWriteWord(handle, 0x10, 0xFFFF);
DapiWriteLong
This command executes a direct register write command to the module.
Description
This command executes a direct register write command to the module.
Definition
void DapiWriteLong(ULONG handle, ULONG adress, ULONG value);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
value=Specifies the data value that is written (32-bit)
Return value
None
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Data is written to register 0x10
DapiWriteLong(handle, 0x10, 0xFFFFFFFF);
DapiWriteLongLong
This command executes a direct register write command to the module.
Description
This command executes a direct register write command to the module.
Definition
void DapiWriteLongLong(ULONG handle, ULONG adress, ULONGLONG value);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
value=Specifies the data value that is written (64-bit)
Return value
None
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Data is written to register 0x10
DapiWriteLongLong(handle, 0x10, 0xFFFFFFFFFFFFFFFF);
DapiReadByte
This command executes a direct register read command on the module.
Description
This command executes a direct register read command on the module.
Definition
ULONG DapiReadByte(ULONG handle, ULONG adress);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
Return value
Content of the register to be read (8-bit)
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programmierbeispiel
// Reads 8 bits from the address 0x0
ULONG data;
data = DapiReadByte(handle, 0x0);
DapiReadWord
This command executes a direct register read command on the module.
Description
This command executes a direct register read command on the module.
Definition
ULONG DapiReadWord(ULONG handle, ULONG adress);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
Return value
Content of the register to be read (16-bit)
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Reads 16 bits from the address 0x0
ULONG data;
data = DapiReadWord(handle, 0x0);
DapiReadLong
This command executes a direct register read command on the module.
Description
This command executes a direct register read command on the module.
Definition
ULONG DapiReadLong(ULONG handle, ULONG adress);
Parameter
handle=This is the handle of an open module
adress=Address to be accessed
Return value
Content of the register to be read (32-bit)
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Reads 32 bits from the address 0x0
ULONG data;
data = DapiReadLong(handle, 0x0);
DapiReadLongLong
This command executes a direct register read command on the module.
Description
This command executes a direct register read command on the module.
Definition
ULONGLONG DapiReadLongLong(ULONG handle, ULONG address);
Parameter
handle=This is the handle of an open module
address=Address to be accessed
Return value
Content of the register to be read (64-bit)
Remark
This should only be used by experienced programmers. This allows direct access to all available registers.
Programming example
// Reads 64 bits from the address 0x0
ULONGLONG data;
data = DapiReadLongLong(handle, 0x0);
Error handling
DapiGetLastError
This function returns the last error recorded.
Description
This function returns the last recorded error. If an error has occurred, it must be cleared with DapiClearLastError(), otherwise every call to DapiGetLastError() will return the "old" error.
If several modules are to be used, the use of DapiGetLastErrorByHandle() is recommended.
Definition
ULONG DapiGetLastError(void);
Parameter
None
Return value
Error code
0=no error. (see delib_error_codes.h)
Programming example
BOOL IsError()
{
unsigned char msg[500];
unsigned long error_code = DapiGetLastError();
if (error_code != DAPI_ERR_NONE)
{
DapiGetLastErrorText((unsigned char*) msg, sizeof(msg));
printf("Error Code = 0x%x * Message = %s\n", error_code, msg);
DapiClearLastError();
return TRUE;
}
return FALSE;
}
DapiGetLastErrorByHandle
This function returns the last error recorded for a specific module using the handle.
Description
This function returns the last error recorded for a specific module using the handle. If an error has occurred, it must be cleared with DapiClearLastErrorByHandle(), otherwise every call to DapiGetLastErrorByHandle() will return the "old" error.
Definition
ULONG DapiGetLastErrorByHandle(ULONG handle);
Parameter
handle=This is the handle of an open module
Return value
Error code
0=no error. (see delib_error_codes.h)
Programming example
BOOL IsError(ULONG handle)
{
unsigned long error_code = DapiGetLastErrorByHandle(handle);
if (error_code != DAPI_ERR_NONE)
{
printf("Error detected on handle 0x%x - Error Code = 0x%x\n", handle, error_code);
DapiClearLastErrorByHandle(handle);
return TRUE;
}
return FALSE;
}
DapiGetLastErrorText
This function reads out the text of the last error recorded.
Description
This function reads out the text of the last recorded error. If an error has occurred, it must be cleared with DapiClearLastError(), otherwise every call to DapiGetLastErrorText() will return the "old" error.
Definition
ULONG DapiGetLastErrorText(unsigned char * msg, unsigned long msg_length);
Parameter
msg = Buffer for the text to be received
msg_length = Length of the text buffer
Programming example
BOOL IsError()
{
unsigned char msg[500];
unsigned long error_code = DapiGetLastError();
if (error_code != DAPI_ERR_NONE)
{
DapiGetLastErrorText((unsigned char*) msg, sizeof(msg));
printf("Error Code = 0x%x * Message = %s\n", error_code, msg);
DapiClearLastError();
return TRUE;
}
return FALSE;
}
DapiClearLastError
This function deletes the last error that was recorded with DapiGetLastError().
Description
This function deletes the last error that was recorded with DapiGetLastError().
Definition
void DapiClearLastError(void);
Parameter
None
Return value
None
Programming example
BOOL IsError()
{
unsigned char msg[500];
unsigned long error_code = DapiGetLastError();
if (error_code != DAPI_ERR_NONE)
{
DapiGetLastErrorText((unsigned char*) msg, sizeof(msg));
printf("Error Code = 0x%x * Message = %s\n", error_code, msg);
DapiClearLastError();
return TRUE;
}
return FALSE;
}
DapiClearLastErrorByHandle
This function deletes the last error of a specific module (handle) that was recorded with DapiGetLastErrorByHandle().
Description
This function deletes the last error of a specific module (handle) that was registered with DapiGetLastErrorByHandle().
Definition
void DapiClearLastErrorByHandle(ULONG handle);
Parameter
handle=This is the handle of an open module.
Return value
None
Programming example
BOOL IsError(ULONG handle)
{
unsigned long error_code = DapiGetLastErrorByHandle(handle);
if (error_code != DAPI_ERR_NONE)
{
printf("Error detected on handle 0x%x - Error Code = 0x%x\n", handle, error_code);
DapiClearLastErrorByHandle(handle);
return TRUE;
}
return FALSE;
}
Test functions
DapiPing
This command checks the connection to an open module.
Description
This command checks the connection to an open module.
Definition
ULONG DapiPing(ULONG handle, ULONG value);
Parameter
handle=This is the handle of an open module
value=Transferred test value, in the value range of 0-255 (8-bit), to the module
Return value
The test value transferred with "value" must be returned here
Web interface
All DEDITEC Ethernet modules feature a web interface that allows you to conveniently configure settings via your web browser and also provides direct access to the I/Os.
This means you can access the product using a smartphone, tablet, or PC via a browser.
The following I/O units are supported:
- Digital inputs
- Digital inputs (counter function)
- Digital outputs
- Analog inputs (voltage & current)
- Analog outputs (voltage & current)
- PT100 temperature measurement
- stepper motor control
With a user system and optional encryption system, you can protect the Ethernet module against unauthorized access.
General
Home page of the web interface. The navigation bar on the left-hand side gives you access to various settings options.

Network configuration
All network settings can be configured directly via the web interface..

Usermanager
Here, you can specify the user name and password for accessing the web interface. If the user is inactive, they will be automatically logged out after the session time expires.

Status / Reboot
Version of the installed firmware. Functions for restarting and resetting the settings.

Security
In addition to a user/password system for the web interface, we also offer you the option of encrypting all network communication. Access to the I/Os can also be blocked.

Supported I/Os
Below, we show you the supported I/Os that you can operate via the web interface.
Digital Inputs
The image shows an overview of the digital inputs. You can switch between multiple inputs using the drop-down menu. The “State” column shows whether a signal is present at the input.

Digital Inputs Counter
Our digital inputs have a counting function. The meter reading can be read and reset via the web interface.

Digital Outputs
The digital outputs can be switched using an on/off button. The current status of the outputs can be read back via the “Readback” column.

Analog Inputs
Current and voltage can also be read via the web interface. The desired operating mode can be set via the A/D Mode drop-down menu.

Analog Outputs
Analog signals can also be output via the web interface. As with the analog inputs, the desired D/A mode can be set using the drop-down menu. The desired value can be written to the outputs using the ‘SET’ button. The ‘Readback’ column shows the current voltage/current output of the D/A converter.

Temperature measurement (PT100)
Temperature measurement is supported by our RO series.
PT100
The current temperature can be read. If no sensor is connected to the channel, this is indicated by ‘disconnected’.

Stepper-Motor Control
The position and speed of the stepper motor can be set using the control elements. The status window shows the current position, temperature, and power supply.

I/O-Control APP for Android™
Control the digital and analog I/Os of our Ethernet modules remotely while on the go. With the DEDITEC I/O-Control Android app, any network-enabled Android device becomes a remote control for DEDITEC products equipped with an Ethernet interface.
Features:
- Save network settings for private and public networks
- Switch digital outputs on and off
- Read digital inputs
- Retrieve status changes and digital input (DI) counters
Supported I/Os:
- Up to 128 digital inputs and outputs


Network settings
In the network settings, the Ethernet configuration of the module to be accessed can be saved.
The following settings can be configured:
- IP address
- TCP port
- Timeout
- TCP encryption type
- Password

Network Search Function

Digital outputs
In the digital outputs section, the channels can be switched on and off.
In addition, the current status of the outputs is displayed as readback information.

Digital inputs
The digital inputs are polled at an adjustable interval.

Analog inputs
The A/D channels are polled automatically. The current A/D value is displayed in the "Value" field.

Analog outputs
The D/A view allows you to conveniently control the module’s analog outputs. First, select the desired D/A mode. You can then enter an output value for each output channel, which will be output by the module once it is transmitted.
The “Readback” field displays the value currently read back from the module for the respective channel. This allows you to verify at any time which value is actually being output.
The “Set test values” button automatically enters test values for all channels. This function is particularly useful for quickly testing the outputs or verifying the module’s operation.

Diagnostics

Screwless connector system
The customer-side connection wiring of the inputs and outputs is carried out using screwless, pluggable terminal strips. The conductor connection is made using a so-called actuating tool.
A locking and ejecting mechanism facilitates the insertion and removal of the complete terminal strip.
Handling:
Steps 1-5
Step 1
See the scope of delivery for the operating tool.

Step 2
Insert the operating tool firmly into the side opening in the direction of the conductor connection.

Step 3
Now insert the stripped conductor into the open clamp contact.

Step 4
Pull out the operating tool again.

Step 5
Check that the conductor is properly connected. It should now no longer be possible to pull it out easily.

Manual
Manual NET series
Quickstart - Hardware description - Software description - ICT-Tool
- Safety instructions
- Installing the drivers
- Connecting the power supply
- Connecting to the PC or network
- Connecting the I/O connectors
- Function test
Hardware description
- List of technical data
- Definition of the LEDs
- Functions of switches and buttons
- Pin assignment of the connectors
- Connection examples
Software description
- Control options via the DELIB, protocol level, DELIB CLI, graphical applications
- DELIB Driver Library, DELIB Sample Sources, DELIB for Linux
- Web interface (only for Ethernet modules)
- DELIB API and its functions
ICT-Tool
- Add module on the PC
- Configure module/interface (Ethernet, USB, CAN, serial)
- Setting options for M2M and event control (only for supported modules)
- Test and diagnose module
- Install firmware updates
- Save/load module configurations using a separate file
Software packages ICT-Tool / DELIB driver library
ICT-Tool + DELIB for Windows (64-bit)
For Windows 11/10, Windows 7, Windows 8, Vista, XP and 2000
Software package for the 64-bit version of the ICT-Tool and the DELIB driver library.
The following operating systems are compatible:
64-bit:
- Windows 10/11 x64
- Windows 8 x64
- Windows 7 x64
- Windows Server 2012 x64
- Windows Server 2008 x64
- Windows Vista x64
- Windows XP x64
- Windows Server 2003 x64
- Windows 2000 x64
Supplied software
ICT-Tool x64
- Updating the DEDITEC module-firmware
- Assigning module addresses
- Module-specific settings
- Configuration of CAN modules
- Test and diagnosis of module functions
- Configuration of the watchdog stick
Replaces the following software
- DT-Flasher x64
- DELIB Module Demo x64
- CAN Configuration Utility x64
- DELIB Module Config x64
- DELIB Configuration Utility x64
- Watchdog Configuration Utility x64
DELIB Command Line Interface x64
Enables the execution of DELIB commands in the command line.
ICT-Tool + DELIB for Windows (32-bit)
For Windows 11/10, Windows 7, Windows 8, Vista, XP and 2000
Software package for the 32-bit version of the ICT-Tool and the DELIB driver library.
The following operating systems are compatible:
32-bit:
-
-
- Windows 10/11
- Windows 8
- Windows 7
- Windows Server 2012
- Windows Server 2008
- Windows Vista
- Windows XP
- Windows Server 2003
- Windows 2000
-
Supplied software
ICT-Tool x32
-
-
- Updating the DEDITEC module-firmware
- Assigning module addresses
- Module-specific settings
- Configuration of CAN modules
- Test and diagnosis of module functions
- Configuration of the watchdog stick
-
Replaces the following software
-
-
- DT-Flasher
- DELIB Module Demo
- CAN Configuration Utility
- DELIB Module Config
- DELIB Configuration Utility
- Watchdog Configuration Utility
-
Attention:
With this version of the driver library, only 32-bit applications can be created, which can then be executed on 32- and 64-bit systems.
DELIB driver library for Linux (32/64-bit)
For 32/64-bit Linux distributions from kernel 2.6.x. Version 2.73 from 28.10.2024
DELIB driver library for Linux distributions (32/64-bit) from kernel 2.6.x
This driver package contains the following components
- DELIB USB driver
- DELIB Ethernet driver
- DELIB CLI
DELIB USB driver
Support for the following products:
- NET series (via USB interface)
- RO-USB series
- BS-USB series
- USB mini-sticks
- USB watchdog
- USB-OPTION-8 / USB-RELAY-8
- USB-TTL-32 / USB-TTL-64
Note:
With the standard version of the USB driver, several USB products with different module IDs (e.g. one RO-USB and one USB-OPTOIN-8) can be addressed. No further driver installation is required.
If several USB products with the same module ID (e.g. a USB-OPTOIN-8 and a USB-RELAIS-8) are to be addressed, the Linux FTDI driver must also be installed. You can find the FTDI driver at http://www.ftdichip.com.
DELIB Ethernet driver
Support for the following products:
- NET series (via Ethernet interface)
- RO-ETH series
- RO-ETH/LC series
- BS-ETH series
- ETH-OPTION-8 / ETH-RELAY-8
- ETH-TTL-64
DELIB CLI
With the DELIB CLI (Command Line Interface) for Linux, all commands for digital and analog I/Os can be set directly via the command line
Manual
Manual for ICT-Tool and DELIB
Software Description - ICT-Tool - DELIB API Reference
Software Description
- Control options via DELIB, protocol level, DELIB CLI, graphical applications
- DELIB driver library, DELIB sample sources, DELIB for Linux
- Web interface (only for Ethernet modules)
- DELIB API and its functions
ICT-Tool
- Add module to PC
- Configure module/interface (Ethernet, USB, CAN, Serial)
- Settings for M2M and Event Control (only for supported modules)
- Test and diagnose module
- Install firmware updates
- Save/load module configurations using a separate file
DELIB API Reference
- Directory structure of DELIB
- Management functions
- Error handling
- Manage digital inputs and outputs
- Manage analog inputs and outputs
- Manage software FIFO
- Manage output timeout
- Register read and write commands
Download
Hardware updates (firmware flash file package)
Firmware flash file package for the ICT tool
This package contains the latest firmware files for the following product series:
- STARTER series
- BS series
- RO series
- NET series
- UC series
- CAN-IO-Box
- Development accessories
The firmware flash file package can alternatively be downloaded via the ICT tool.
CAD files
CAD data for enclosures
- UC series
- NET series
Simplified 3D model of the item
- 3D model for the electronics enclosure - ME MAX 22.5 U-U1 BK by Phoenix Contact©
- Item No. 2279541
- Width: 22.6 mm, Height: 99 mm, Depth: 113.65 mm
- Color: black (similar to RAL 9005)
USB cable A plug to B plug
USB cable for connecting our modules to the control PC.
- Type: USB 2.0, A plug to B plug
- Length: 1,8 m

4-pin plug connector
Enables the power supply unit to be connected to the DEDITEC module.
- Type: Phoenix Contact® - 1893313
- 100 % mismatch protected
- For all conductor types from 0.2 mm² to 2.5 mm²

DIN-Rail connector
The DIN rail connector is a single BUS segment that enables connection to other modules. It is clipped into the top-hat rail and plugged onto the side of an existing DIN rail connector.
- Type: Phoenix Contact® - 2203852
- Connection of a NET or UC module
- For expanding the NET or UC bus system
- 1 Piece
USB cable A plug to B plug
USB cable for connecting our modules to the control PC.
- Type: USB 2.0, A plug to B plug
- Length: 1,8 m
4-pin plug connector
Enables the power supply unit to be connected to the DEDITEC module.
- Type: Phoenix Contact® - 1893313
- 100 % mismatch protected
- For all conductor types from 0.2 mm² to 2.5 mm²
DIN-Rail connector
The DIN rail connector is a single BUS segment that enables connection to other modules. It is clipped into the top-hat rail and plugged onto the side of an existing DIN rail connector.
- Type: Phoenix Contact® - 2203852
- Connection of a NET or UC module
- For expanding the NET or UC bus system
- 1 Piece
Top hat rail
Top-hat rail for mounting our control technology modules.
- DIN rail according to DIN EN 50022
- Type: Phoenix Contact® - 1208131
- Dimensions in mm: 450 x 35 x 7.5 (L x W x H)

24V/2A power supply unit for top-hat rail mounting
The DR-4524 from Mean Well is a 48W power supply unit for DIN rail mounting for industrial applications. It offers protection against short circuit, overload, overvoltage and overheating.
- Input voltage range: 85 V.. 264 V AC / 120 V DC ... 370 V DC
- Output voltage: 24 V DC
- Output current: 2 A
- Rated power: 48 W

Typical Application Areas of the NET-CPU-BASE/PRO
The NET-CPU-BASE/PRO is suitable for industrial applications where digital and analog signals need to be acquired, output or integrated decentrally into higher-level measurement, control and automation environments. As the central base module of the DEDITEC NET series, the interface unit connects Ethernet with TCP/IP and Modbus TCP to modular I/O submodules. This makes the system particularly suitable for scalable remote I/O architectures in machines, plants, test benches and control cabinets.
Suitable for
- Machine and plant engineering
- Industrial automation and decentralized automation
- Control cabinet construction and DIN-rail I/O systems
- Test benches, test systems and quality assurance
- Industrial data acquisition and process monitoring
- Measurement, control and automation tasks
- Modular remote I/O stations with Ethernet and Modbus TCP
- Edge-oriented data acquisition in distributed I/O systems
- Special-purpose machinery, development and technical integration
- Modernization of existing automation and measurement systems
Typical Applications
- Decentralized acquisition of digital and analog signals via modular I/O submodules
- Building modular Modbus TCP remote I/O stations for machines, plants and test benches
- Ethernet-based process data acquisition in industrial network environments
- Expanding existing measurement, control and automation systems with flexible I/O structures
- Control cabinet integration via DIN rail bus / NET bus with modular expandability
- Connecting I/O signals to higher-level automation, measurement or visualization systems
- Test bench setups with distributed inputs and outputs
- Diagnostic, test and development environments with configurable interfaces
- Decentralized monitoring of signal states, communication, error events and timeout conditions
- Automation tasks with event control, timer functions, FIFO buffering and fail-safe behavior
Typical Signal and Switching Tasks
- Acquiring digital input states via suitable I/O submodules
- Outputting digital switching signals via modular output modules
- Acquiring analog measurement values via suitable A/D submodules
- Outputting analog setpoints via suitable D/A submodules
- Transmitting process, status and measurement data via Ethernet, TCP/IP and Modbus TCP
- Buffering continuous measurement data using FIFO functionality
- Time-controlled switching of outputs via timer functions
- Executing simple if-then sequences via event control
- Defining safe output states in timeout or communication failure scenarios
- Expanding distributed I/O systems via NET bus and DIN rail bus
Comparison: Modular Modbus TCP Remote I/O System – NET-CPU-BASE/PRO
The following comparison classifies the NET-CPU-BASE/PRO technically: as the central base module of the DEDITEC NET series for building modular remote I/O stations with Ethernet, TCP/IP and Modbus TCP. The focus is on the system architecture with I/O submodules, industrial network integration, modular expandability, diagnostic and safety functions, and integration into measurement, control and automation environments.
Product Type, System Architecture and Remote I/O Usage |
|||
| Feature | Market Comparison | NET-CPU-BASE/PRO | Practical Benefit |
|---|---|---|---|
| Product Type | Many I/O solutions are designed as fixed single modules with predefined input and output channels. | Central base module for a modular Modbus TCP remote I/O system of the DEDITEC NET series. | Suitable when a scalable remote I/O architecture with expandable I/O submodules is required instead of a rigid single-module solution. |
| System Role | In classic I/O modules, communication and signal levels are often combined in one device. | Interface and communication unit between Ethernet/TCP/IP networks and modular I/O submodules. | Communication and signal levels can be planned separately; the I/O structure can be built using suitable submodules depending on the application. |
| Modular Expandability | In many compact I/O modules, the channel count is fixed by the device variant. | Expansion via NET bus / DIN rail bus for connecting additional NET modules. | Supports step-by-step construction of modular I/O stations in control cabinet, machine and test bench environments. |
| Signal Level | Single modules are often limited to specific signal types or channel types. | Digital and analog signals are implemented via suitable I/O submodules of the NET series. | A system can be assembled with suitable submodules for different measurement, control and automation tasks. |
| Typical Application Environment | Many I/O modules are described generally for automation tasks without clearly defining the system architecture. | Modular remote I/O stations for industrial automation, decentralized data acquisition, test benches, mechanical engineering and control cabinet integration. | The product role is clearly defined: central communication unit for distributed I/O structures instead of a single fixed I/O end device. |
Ethernet, Modbus TCP and Interface Integration |
|||
| Feature | Market Comparison | NET-CPU-BASE/PRO | Practical Benefit |
| Ethernet Communication | Industrial I/O systems differ significantly in interface type, protocol support and network capability. | 10/100 Mbit/s Ethernet with TCP/IP and Modbus TCP. | Enables integration into Ethernet/TCP/IP-based automation, measurement and data acquisition environments. |
| Modbus TCP | Not every Ethernet I/O solution supports an open, widely used industrial communication protocol. | Modbus TCP for data exchange over Ethernet. | Simplifies integration into existing Modbus TCP environments and higher-level measurement, control or visualization systems. |
| Network Configuration | Configuration of industrial Ethernet modules varies by manufacturer (tools, web interfaces, direct commands). | LAN configuration via ICT tool; IP address via DHCP or static. | Supports traceable commissioning and simplifies adaptation to existing network structures. |
| DIP Switches | Basic functions are often only accessible via software or require separate configuration paths. | DIP switches for DHCP ON/OFF, write protection ON/OFF, start with factory settings and bootloader start. | Simplifies service, commissioning and restoring defined device states directly on the module. |
| Access Speed | Practical access speed depends on protocol, driver, network and application. | Average access time from PC to module: 1 ms, measured with 1000 accesses via DELIB using DapiDoSet32. | Helps evaluate PC-based measurement, control and test applications with frequent I/O access. |
| USB Interface | Not every Ethernet or remote I/O system offers an additional local interface for setup and service. | USB Type B with USB 2.0 / USB 1.1 up to 480 Mbit/s. | Supports local commissioning, parameterization and testing without relying solely on network communication. |
| CAN Interface | Additional CAN functions are not always integrated or require separate components. | CAN 2.0A or CAN 2.0B via 9-pin D-sub, bit rates from 10 kbit/s to 1 Mbit/s, open CAN protocol and Auto-TX/RX mode. | Expands integration options for CAN-based machine, test bench or automation environments. |
| Serial Interfaces | RS-232 and RS-485 are not always provided in modern Ethernet I/O systems. | RS-232 and RS-485 via 9-pin D-sub connectors up to 115,200 baud; RS-485 according to TIA/EIA-485-A. | Simplifies integration of serial devices, existing system components or project-specific interface environments. |
Signal Processing, Diagnostics and Operational Safety |
|||
| Feature | Market Comparison | NET-CPU-BASE/PRO | Practical Benefit |
| Event Control | In simple remote I/O modules, event logic often must be implemented entirely in an external application. | Event control for linking events with actions using if-then logic directly in module memory. | Supports simple decentralized control and monitoring tasks without fully external programming. |
| FIFO Function | Continuous measurement data transmission can fluctuate due to network traffic or polling cycles. | FIFO function for buffering continuous measurement data on the module and transmitting it over Ethernet. | Supports smoother data transmission and improves usability in continuous measurement and test workflows. |
| A/D Software Filter | Interference on analog measurement signals must often be handled externally. | A/D software filter for smoothing and optimizing electrical interference in analog measurement signals. | Helps stabilize analog values in electrically demanding measurement and automation environments. |
| Timer Function | Time-controlled switching often must be implemented entirely in control software. | Automatic switching of outputs within freely definable time intervals. | Simplifies recurring switching tasks and supports defined workflows in test, inspection and automation applications. |
| Fail-Safe Function | Output behavior during communication failure varies widely and must be checked per system. | Software-configurable timeout protection; outputs can be activated, deactivated or left unchanged. | Supports defined output states during communication issues and increases predictability in fault scenarios. |
| Timeout Modes | Timeout behavior differs by system regarding reactivation and output locking. | Timeout modes “Normal”, “Auto reactivate” and “Secure Outputs”. | Allows adapting timeout behavior to different safety, service and automation requirements. |
| Status Indicators | Diagnostic information is often limited or only available via software. | LEDs for DIN rail bus communication, module status, Ethernet activity, USB activity, interface status, error, input state change and timeout shutdown; CAN and SER activity on NET-CPU-PRO-CS. | Simplifies commissioning, service and troubleshooting directly on the module. |
| Galvanic Isolation | Electrical isolation varies widely across industrial I/O systems. | Ethernet isolated up to 1.5 kV AC; CAN, RS-232 and RS-485 isolated up to 500 V. | Reduces risks from potential differences and supports use in industrial control cabinet, machine and test bench environments. |
Mechanics, Mounting and Control Cabinet Integration |
|||
| Feature | Market Comparison | NET-CPU-BASE/PRO | Practical Benefit |
| Power Supply | Industrial I/O modules are typically designed for DC supply ranges that must be checked per system. | +7 V DC … +24 V DC; also powers the DIN rail bus. | Supports operation in industrial DC environments and powers the modular DIN rail bus. |
| Current Consumption | Power consumption affects cabinet planning, supply design and thermal evaluation. | Max. 90 mA / 24 V. | Simplifies electrical design of modular I/O stations in control cabinets or test benches. |
| Mounting | Depending on the I/O system, additional adapters or special housings may be required. | DIN rail mounting 35 × 7.5 mm and DIN rail bus for modular expansion. | Simplifies building compact remote I/O stations in control cabinets, machines and test benches. |
| Terminal Block | Wiring and service depend heavily on terminal type, conductor size and plug-in capability. | Phoenix Contact 1893313 for power supply; supports 0.2 mm² … 2.5 mm²; pluggable. | Supports service-friendly wiring and simplifies installation, replacement and commissioning. |
| Memory and RTC | Additional memory or time functions are not always available in simple I/O modules. | Micro SD card slot and battery-buffered real-time clock (CR2032). | Useful for applications requiring local storage or time functions for configuration, sequencing or diagnostics. |
| Operating Temperature | Temperature ranges must be evaluated for cabinet, test field or lab environments. | +10 °C … +50 °C. | Suitable for typical industrial indoor, cabinet, test bench and laboratory environments. |
| Dimensions | Available space is a key planning factor in modular I/O stations and cabinet layouts. | 117 mm × 22.5 mm × 111 mm (H × W × D). | Compact module width supports space-saving DIN rail installations with modular expansion. |
Software, Commissioning and Service |
|||
| Feature | Market Comparison | NET-CPU-BASE/PRO | Practical Benefit |
| ICT Tool | Many I/O systems require multiple tools for setup, diagnostics, testing or firmware maintenance. | ICT tool for integration, configuration, testing, diagnostics and firmware updates. | Simplifies commissioning, testing and maintenance through a unified software environment. |
| DELIB Driver Library | Software integration varies by manufacturer and may be limited to specific platforms or libraries. | Access via DELIB driver library and API for various programming environments. | Simplifies integration into custom measurement, test bench, control and automation software. |
| Command-Line Interface | Automated tests and service processes may require additional software or custom scripts. | CLI for products with Ethernet or USB interface; supports digital and analog I/O. | Enables script-based tests, commissioning workflows and service processes under Windows and Linux. |
| Software Maintenance | Updates for tools, drivers or libraries may be limited or product-dependent. | Free updates and software maintenance according to existing comparison content. | Supports long-term maintenance of measurement, control and automation software across the product lifecycle. |
Manufacturer, Availability and Support |
|||
| Feature | Market Comparison | NET-CPU-BASE/PRO | Practical Benefit |
| Production Location | In industrial electronics, origin, manufacturing depth and supply chains vary widely. | Made in Germany. | Relevant for B2B applications requiring traceable manufacturing, technical coordination and long-term project planning. |
| Long-Term Availability | Product lifecycles and availability vary significantly across automation components. | 10 years guaranteed. | Supports plant engineering, series machinery, retrofit projects and test bench systems requiring predictable spare parts availability. |
| Support Quality | Support may be provided via sales, standard documentation, external service providers or general channels. | Direct developer support. | Helpful for interface questions, commissioning, special applications and technical coordination. |
Häufig gestellte Fragen (FAQ)
THROUGH WHICH SOFTWARE INTERFACES IS THE NET-CPU-BASE/PRO CONTROLLED?
USB models are integrated into software via the DEDITEC DELIB driver library. Ethernet models can, in addition to the DELIB library, also be accessed directly via TCP/IP, Modbus TCP, or the web interface.
HOW CAN THE MODULES BE CONFIGURED, TESTED, AND UPDATED?
Configuration, diagnostics, and commissioning are conveniently performed using the DEDITEC ICT-Tool. It also allows functions to be tested and firmware updates to be carried out.
WHERE CAN I FIND CURRENT DOCUMENTATION AND TECHNICAL RESOURCES?
Current manuals, technical documentation, and other product-specific materials can be found directly on the product page under "Downloads and Manuals". In addition, these documents are also available for download in the central download section of the DEDITEC homepage.
WHERE CAN I FIND EXAMPLES FOR SOFTWARE-BASED CONTROL OF THE MODULE?
Examples for controlling the module, as well as information about supported programming languages and libraries, can be found in the module documentation and on the DEDITEC website in the "Software" section under "Control and Programming".
You might also like …
-

CANopen digital I/O (DIO) module * CANopen module with 8 digital inputs/outputs
€ 289,77 Incl. 19% VAT plus shipping View Product -
Ethernet Modbus TCP I/O module * 8 optocoupler inputs and 8 digital outputs, web interface (Modbus TCP-compatible)
Price range: € 360,57 through € 374,85 Incl. 19% VAT plus shipping View Product -
CAN bus relay * CAN module with 16 digital outputs
Price range: € 398,65 through € 439,11 Incl. 19% VAT plus shipping View Product


You might also like …
-
CANopen digital I/O (DIO) module * CANopen module with 8 digital inputs/outputs
€ 289,77 Incl. 19% VAT plus shipping View Product -
Ethernet Modbus TCP I/O module * 8 optocoupler inputs and 8 digital outputs, web interface (Modbus TCP-compatible)
Price range: € 360,57 through € 374,85 Incl. 19% VAT plus shipping View Product